Events
retrieve:
Return the details about the given Memento id.
list:
List all Memento objects.
GET /api/v1/mementos/417/events/?format=api&ordering=en_label
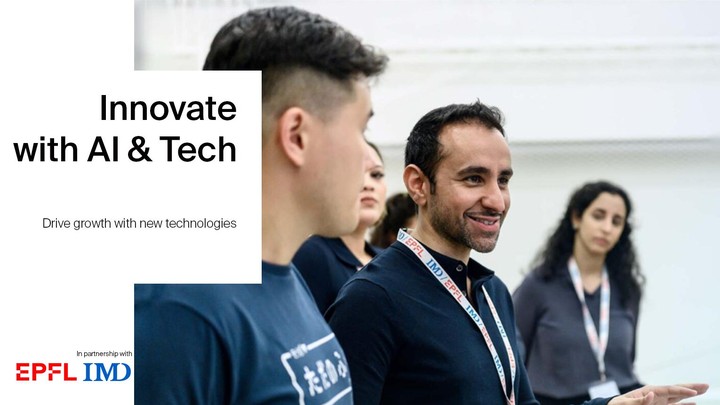
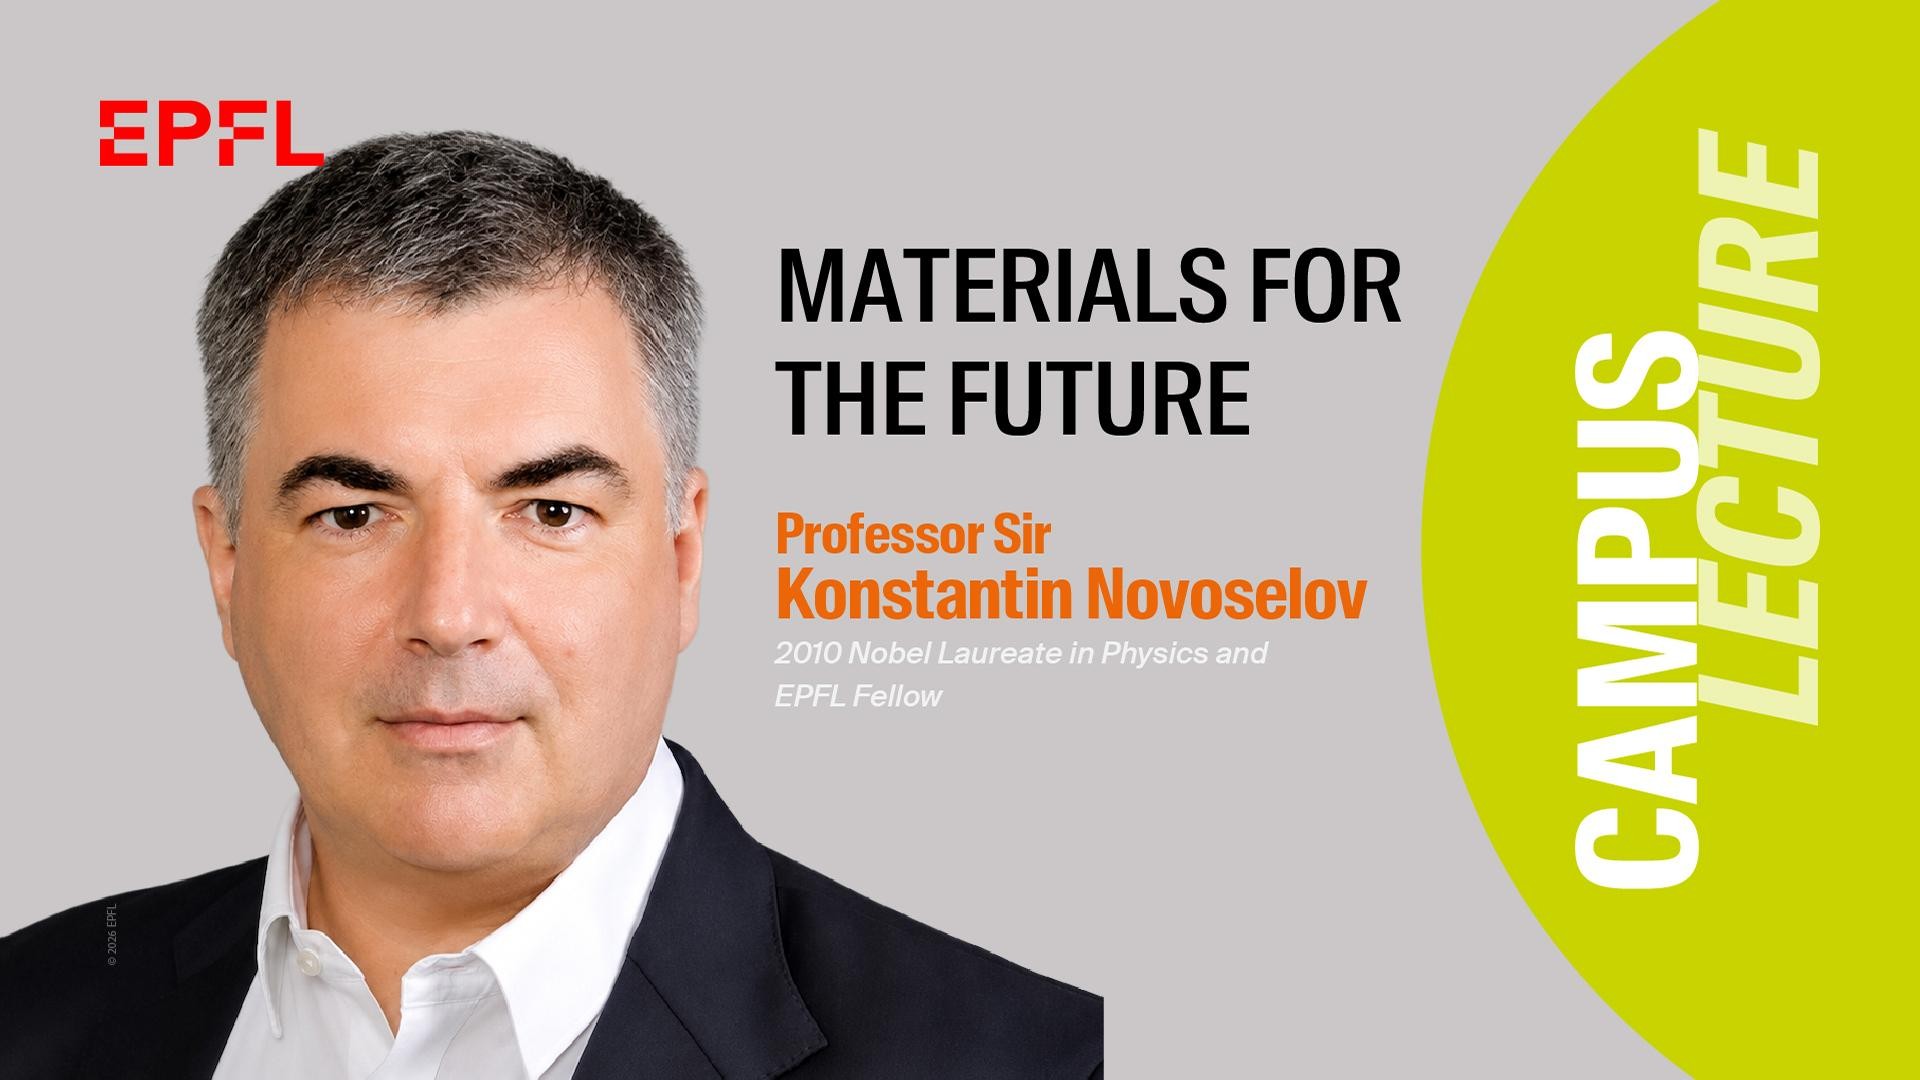
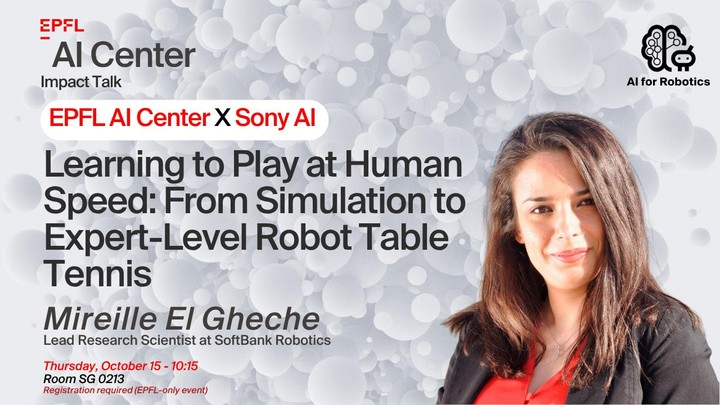
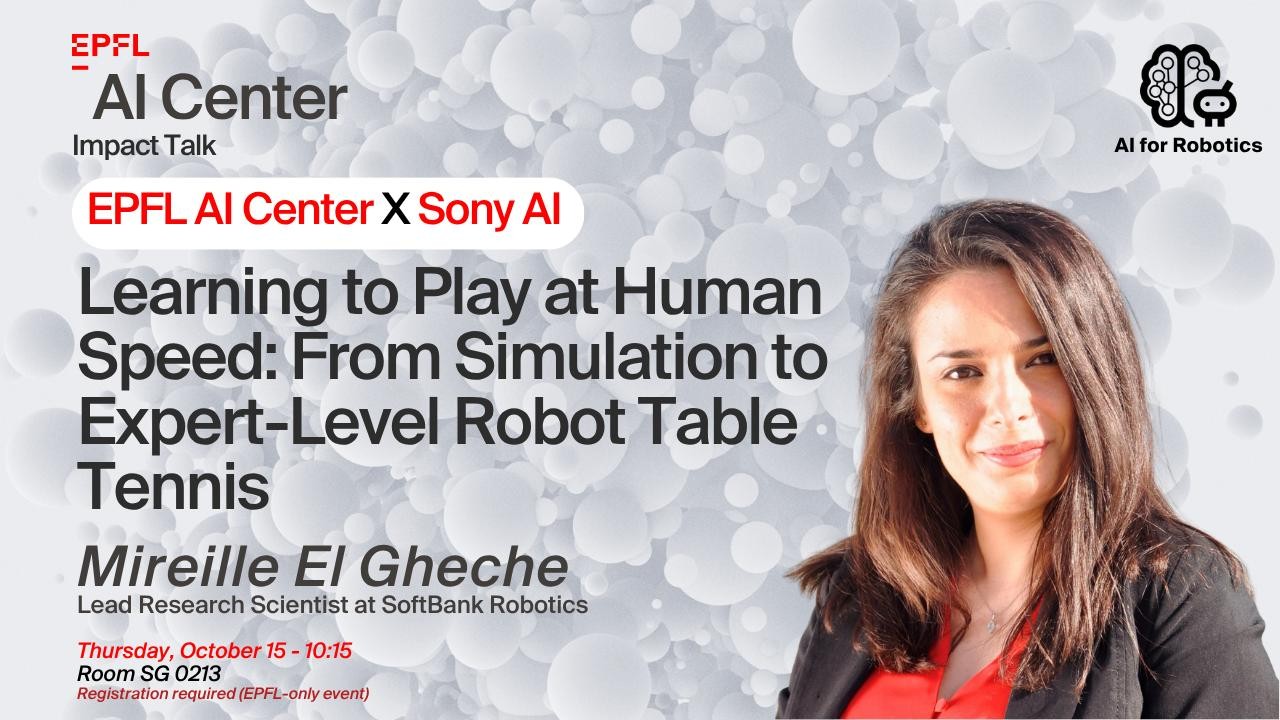
{ "count": 10, "next": null, "previous": null, "results": [ { "id": 72452, "title": "MechE Colloquium: From Motion to Mission Planning via Augmented Graphs of Convex Sets", "slug": "meche-colloquium-from-motion-to-mission-planning-v", "event_url": "https://memento.epfl.ch/event/meche-colloquium-from-motion-to-mission-planning-v", "visual_url": "https://memento.epfl.ch/image/33700/200x112.jpg", "visual_large_url": "https://memento.epfl.ch/image/33700/720x405.jpg", "visual_maxsize_url": "https://memento.epfl.ch/image/33700/max-size.jpg", "lang": "en", "start_date": "2026-10-06", "end_date": "2026-10-06", "start_time": "12:00:00", "end_time": "13:00:00", "description": "<strong>Abstract: </strong>Robot motion planning has traditionally focused on navigating obstacle-laden environments: computing smooth, collision-free trajectories from start to goal. Many real-world missions, however, require satisfying logical precedence constraints: collecting resources before accessing restricted zones, completing subtasks in a prescribed order, or acquiring tools before they can be used. This talk presents the augmented graph of convex sets (augmented GCS) framework, which unifies continuous trajectory optimization and combinatorial task sequencing within a single optimization problem.<br>\r\nThe key insight is that a layered augmented GCS, built on an exact convex partition of the free space, simultaneously selects an optimal task completion sequence and computes an optimal continuous trajectory. A shortest path in the augmented GCS solves both problems at once, yielding an exact solution up to a finite Bézier curve parameterization. The layered structure of the augmented GCS turns out to implement precisely the Bellman-Held-Karp (BHK) dynamic programming algorithm for the Traveling Salesman Problem, establishing a formal correspondence between our framework and the combinatorial TSP literature. This makes augmented GCS a continuous-geometry generalization of BHK, achieving the same singly exponential worst-case complexity, an exponential improvement over general-purpose temporal logic tools. We further develop a library of mission specification variations (including ordered collection, disjunctive keys, conjunctive doors, timed constraints, and conditional logic) each with proven correctness, substantially expanding the range of expressible mission types. Numerical experiments confirm exponential speedups in practice and near-global-optimality on a large benchmark suite.<br>\r\nTime permitting, I will briefly discuss ongoing extensions, including spacetime augmented GCS for dynamic environments, safety-aware planning via conformal prediction sets, and a galactic survey benchmark inspired by space mission planning that stress-tests the framework at scale.<br>\r\n<br>\r\n<br>\r\n<br>\r\n<strong>Biography: </strong>Tyler Summers is an associate professor at the University of Texas at Dallas. Prior to joining UT Dallas, he was an ETH Postdoctoral Fellow at the Automatic Control Laboratory at ETH Zurich from 2011 to 2015. He received a PhD degree in Aerospace Engineering at the University of Texas at Austin in 2010. He was a Fulbright Postgraduate Scholar at the Australian National University in Canberra, Australia in 2007-2008. He received the National Science Foundation CAREER Award in 2021 and a Young Investigator Program award from the US Army Research Office in 2017. His research interests are in feedback control, optimization, and learning in complex dynamical networks, with applications in robotics and power networks.", "image_description": "", "creation_date": "2026-08-26T16:15:39", "last_modification_date": "2026-08-26T16:19:15", "link_label": "", "link_url": "", "canceled": "False", "cancel_reason": "", "place_and_room": "MED 0 1418", "url_place_and_room": "https://plan.epfl.ch/?room==MED%200%201418", "url_online_room": "https://epfl.zoom.us/j/61360740951", "spoken_languages": [ "https://memento.epfl.ch/api/v1/spoken_languages/2/?format=api" ], "speaker": "<a href=\"https://me.utdallas.edu/faculty/tyler-summers/\">Prof. Tyler Summers</a>, <a href=\"https://me.utdallas.edu/\">Mechanical engineering,</a> <a href=\"https://www.utdallas.edu/\">The University of Texas at Dallas</a>", "organizer": "<a href=\"https://people.epfl.ch/maryam.kamgarpour\">Prof. Maryam Kamgarpour</a>", "contact": "<a href=\"mailto:[email protected]\">Institute of Mechanical Engineering</a>", "is_internal": "False", "theme": "", "vulgarization": { "id": 1, "fr_label": "Tout public", "en_label": "General public" }, "registration": { "id": 3, "fr_label": "Entrée libre", "en_label": "Free" }, "keywords": "MechE Colloquium: From Motion to Mission Planning via Augmented Graphs of Convex Sets", "file": null, "icalendar_url": "https://memento.epfl.ch/event/export/121601/", "category": { "id": 1, "code": "CONF", "fr_label": "Conférences - Séminaires", "en_label": "Conferences - Seminars", "activated": true }, "academic_calendar_category": null, "domains": [], "mementos": [ "https://memento.epfl.ch/api/v1/mementos/8/?format=api", "https://memento.epfl.ch/api/v1/mementos/1/?format=api", "https://memento.epfl.ch/api/v1/mementos/232/?format=api", "https://memento.epfl.ch/api/v1/mementos/270/?format=api", "https://memento.epfl.ch/api/v1/mementos/6/?format=api", "https://memento.epfl.ch/api/v1/mementos/417/?format=api", "https://memento.epfl.ch/api/v1/mementos/394/?format=api" ] }, { "id": 70656, "title": "Innovate with AI and Tech", "slug": "innovate-with-ai-and-tech-3", "event_url": "https://memento.epfl.ch/event/innovate-with-ai-and-tech-3", "visual_url": "https://memento.epfl.ch/image/32081/200x112.jpg", "visual_large_url": "https://memento.epfl.ch/image/32081/720x405.jpg", "visual_maxsize_url": "https://memento.epfl.ch/image/32081/max-size.jpg", "lang": "en", "start_date": "2026-10-05", "end_date": "2026-10-09", "start_time": null, "end_time": null, "description": "<strong>Drive growth with new technologies</strong><br>\r\n<br>\r\nEPFL & IMD join forces to offer you a unique learning experience to drive innovation with game-changing technologies like AI, IoT, and robotics.<br>\r\n<br>\r\nNew technologies can greatly enhance your business value, enabling you to develop fresh products and services, boost productivity and save time. However, in a rapidly evolving field, how do you identify which tech solutions offer you the best opportunities to innovate and grow?<br>\r\n<br>\r\nThis 5-day program brings together business and technology experts to help you identify your most promising strategic opportunities using innovative technologies like AI, robotics, and quantum computing. You’ll leverage AI as your innovation partner, enhancing how you develop and validate solutions. You’ll cultivate an innovator’s mindset, gaining cutting-edge knowledge, skills, and the confidence to make impactful technology decisions.<br>\r\n<br>\r\nInnovate with AI and Tech is a must for leaders and managers in all business areas looking to leverage new technologies to drive faster innovation and growth.", "image_description": "", "creation_date": "2025-12-11T09:34:09", "last_modification_date": "2026-03-30T10:09:45", "link_label": "Website", "link_url": "https://www.imd.org/digital-transformation/iait/innovate-ai-technologies/", "canceled": "False", "cancel_reason": "", "place_and_room": "", "url_place_and_room": "", "url_online_room": "", "spoken_languages": [ "https://memento.epfl.ch/api/v1/spoken_languages/2/?format=api" ], "speaker": "", "organizer": "EPFL Executive Education & IMD", "contact": "[email protected]", "is_internal": "False", "theme": "", "vulgarization": { "id": 1, "fr_label": "Tout public", "en_label": "General public" }, "registration": { "id": 1, "fr_label": "Sur inscription", "en_label": "Registration required" }, "keywords": "Innovation, AI, Tech", "file": null, "icalendar_url": "https://memento.epfl.ch/event/export/118976/", "category": { "id": 4, "code": "DIVERS", "fr_label": "Autres types d’événement", "en_label": "Miscellaneous", "activated": true }, "academic_calendar_category": null, "domains": [], "mementos": [ "https://memento.epfl.ch/api/v1/mementos/416/?format=api", "https://memento.epfl.ch/api/v1/mementos/1/?format=api", "https://memento.epfl.ch/api/v1/mementos/3/?format=api", "https://memento.epfl.ch/api/v1/mementos/437/?format=api", "https://memento.epfl.ch/api/v1/mementos/6/?format=api", "https://memento.epfl.ch/api/v1/mementos/417/?format=api", "https://memento.epfl.ch/api/v1/mementos/8/?format=api" ] }, { "id": 72214, "title": "Do Robots Dream of Construction Sites? / ARCHIZOOM x CRCL", "slug": "do-robots-dream-of-construction-sites-archizoom--3", "event_url": "https://memento.epfl.ch/event/do-robots-dream-of-construction-sites-archizoom--3", "visual_url": "https://memento.epfl.ch/image/33494/200x112.jpg", "visual_large_url": "https://memento.epfl.ch/image/33494/720x405.jpg", "visual_maxsize_url": "https://memento.epfl.ch/image/33494/max-size.jpg", "lang": "en", "start_date": "2026-09-09", "end_date": "2026-12-05", "start_time": null, "end_time": null, "description": "<strong>DO ROBOTS DREAM OF CONSTRUCTION SITES?<br>\r\n09.09-05.12.2026<br>\r\n<br>\r\nOpening Tuesday 8 September<br>\r\n6.15pm – </strong>Discussion between Stefana Parascho and Aude Billard, moderated by Pier Vittorio Aureli<br>\r\n<strong>7.30pm –</strong> Opening doors and aperitive<br>\r\n<br>\r\nWhat if robots didn’t replace us, but worked alongside us? Robots are capable of assembling, analysing, experimenting and learning from their mistakes. Could they take on construction work without replacing human labour? Research carried out by the CRCL – Lab for Creative Computation at EPFL explores a form of collaboration between humans and machines that departs from the traditional promise of automation. It opens the way to more inclusive building sites and non-standardised, more environmentally friendly architecture that goes beyond the mere logic of replacement and productivity. <br>\r\n<br>\r\n<strong>An exhibition produced in collaboration with the <a href=\"https://www.crclcrclcrcl.org/\">CRCL – Lab for Creative Computation</a>, led by Stefana Parascho</strong>", "image_description": "", "creation_date": "2026-07-07T11:36:24", "last_modification_date": "2026-07-13T17:08:03", "link_label": "Do Robots Dream of Construction Sites", "link_url": "https://www.epfl.ch/campus/art-culture/museum-exhibitions/archizoom/fr/do-robots-dream-of-construction-sites/", "canceled": "False", "cancel_reason": "", "place_and_room": "Archizoom", "url_place_and_room": "https://plan.epfl.ch/?room==SG%201212", "url_online_room": "", "spoken_languages": [ "https://memento.epfl.ch/api/v1/spoken_languages/1/?format=api", "https://memento.epfl.ch/api/v1/spoken_languages/2/?format=api" ], "speaker": "CRCL - Lab for Creative Computation", "organizer": "Archizoom", "contact": "Cyril Veillon, Solène Hoffmann", "is_internal": "False", "theme": "", "vulgarization": { "id": 1, "fr_label": "Tout public", "en_label": "General public" }, "registration": { "id": 3, "fr_label": "Entrée libre", "en_label": "Free" }, "keywords": "Architecture, Technology, Construction, Robotic, Robots, Travail, Labor, Durability", "file": null, "icalendar_url": "https://memento.epfl.ch/event/export/121235/", "category": { "id": 5, "code": "EXPO", "fr_label": "Expositions", "en_label": "Exhibitions", "activated": true }, "academic_calendar_category": null, "domains": [], "mementos": [ "https://memento.epfl.ch/api/v1/mementos/1/?format=api", "https://memento.epfl.ch/api/v1/mementos/4/?format=api", "https://memento.epfl.ch/api/v1/mementos/6/?format=api", "https://memento.epfl.ch/api/v1/mementos/8/?format=api", "https://memento.epfl.ch/api/v1/mementos/22/?format=api", "https://memento.epfl.ch/api/v1/mementos/32/?format=api", "https://memento.epfl.ch/api/v1/mementos/45/?format=api", "https://memento.epfl.ch/api/v1/mementos/145/?format=api", "https://memento.epfl.ch/api/v1/mementos/417/?format=api" ] }, { "id": 72587, "title": "Performance trade-offs and gait adaptation strategies in undulatory swimming characterised via bio-inspired robotics", "slug": "performance-trade-offs-and-gait-adaptation-strateg", "event_url": "https://memento.epfl.ch/event/performance-trade-offs-and-gait-adaptation-strateg", "visual_url": "https://memento.epfl.ch/image/33832/200x112.jpg", "visual_large_url": "https://memento.epfl.ch/image/33832/720x405.jpg", "visual_maxsize_url": "https://memento.epfl.ch/image/33832/max-size.jpg", "lang": "en", "start_date": "2026-10-09", "end_date": "2026-10-09", "start_time": "17:30:00", "end_time": null, "description": "<p>Thesis Directors: Prof. K. A. J. Mulleners, Prof. A. Ijspeert<br>\r\nMechanics doctoral program<br>\r\nThesis Nr. 11364<br>\r\n<br>\r\nTo take part in the public defense, please contact directly the speaker</p>", "image_description": "", "creation_date": "2026-09-16T08:49:55", "last_modification_date": "2026-09-16T08:49:55", "link_label": "", "link_url": "", "canceled": "False", "cancel_reason": "", "place_and_room": "MED 0 1418", "url_place_and_room": "https://plan.epfl.ch/?room==MED%200%201418", "url_online_room": "", "spoken_languages": [], "speaker": "<strong>Alexandros ANASTASIADIS</strong>", "organizer": "", "contact": "<strong>Alexandros ANASTASIADIS</strong>", "is_internal": "False", "theme": "", "vulgarization": { "id": 1, "fr_label": "Tout public", "en_label": "General public" }, "registration": { "id": 3, "fr_label": "Entrée libre", "en_label": "Free" }, "keywords": "EDME", "file": null, "icalendar_url": "https://memento.epfl.ch/event/export/121808/", "category": { "id": 12, "code": "SOUTE", "fr_label": "Soutenances de thèses", "en_label": "Thesis defenses", "activated": true }, "academic_calendar_category": null, "domains": [], "mementos": [ "https://memento.epfl.ch/api/v1/mementos/1/?format=api", "https://memento.epfl.ch/api/v1/mementos/6/?format=api", "https://memento.epfl.ch/api/v1/mementos/8/?format=api", "https://memento.epfl.ch/api/v1/mementos/417/?format=api" ] }, { "id": 72357, "title": "Materials for the Future", "slug": "materials-for-the-future", "event_url": "https://memento.epfl.ch/event/materials-for-the-future", "visual_url": "https://memento.epfl.ch/image/33729/200x112.jpg", "visual_large_url": "https://memento.epfl.ch/image/33729/720x405.jpg", "visual_maxsize_url": "https://memento.epfl.ch/image/33729/max-size.jpg", "lang": "en", "start_date": "2026-10-09", "end_date": "2026-10-09", "start_time": "18:00:00", "end_time": "19:30:00", "description": "<p>In 2026, EPFL named Professor Konstantin Novoselov its first-ever EPFL Fellow, a newly created honorary title recognising scientific personalities of exceptional international stature.<br>\r\n<br>\r\nEPFL is delighted to host a public lecture to celebrate this nomination of one of the most influential physicists of our time.<br>\r\n<br>\r\nKonstantin Novoselov was awarded the Nobel Prize in Physics in 2010 and is globally renowned for his pioneering work on graphene and two-dimensional materials. By isolating graphene for the first time, a sheet of carbon just one atom thick, he opened an entirely new field of research, with profound implications for electronics, energy and quantum technologies.<br>\r\n<br>\r\n<em>Picture this: it was from the graphite of an ordinary pencil lead that this \"super-material\" was first isolated. Using nothing more than a piece of adhesive tape to peel away a layer a single atom thick, Konstantin Novoselov revealed to the world a material with extraordinary properties. A million times thinner than a human hair, 200 times stronger than steel and remarkably conductive, graphene pushes every limit. From the lead of your pencil to the batteries of tomorrow, join us to discover how a deceptively simple gesture set off a genuine technological revolution.</em><br>\r\n<br>\r\nThis Campus Lecture offers an introduction to that revolution: how a two-dimensional material is transforming our understanding of matter and how today's fundamental discoveries become tomorrow's technologies.<br>\r\n<br>\r\n<strong>About Konstantin Novoselov</strong><br>\r\nKonstantin Novoselov is a physicist specialising in condensed matter and nanotechnology. He conducted his Nobel Prize–winning research at the University of Manchester, where, together with Professor Andre Geim, he isolated graphene for the first time. He has held academic positions in the United Kingdom as well as internationally and is currently based at the National University of Singapore. Widely recognised as a leading figure in the study and application of two-dimensional materials, he has received numerous honours for his contributions to science.</p>", "image_description": "", "creation_date": "2026-08-18T11:48:33", "last_modification_date": "2026-09-01T09:58:59", "link_label": "Inscription", "link_url": "https://forms.cloud.microsoft/e/8wFYA27p68", "canceled": "False", "cancel_reason": "", "place_and_room": "RLC E1 240", "url_place_and_room": "https://plan.epfl.ch/?room==RLC%20E1%20240", "url_online_room": "", "spoken_languages": [ "https://memento.epfl.ch/api/v1/spoken_languages/2/?format=api" ], "speaker": "Prof. Konstantin Novoselov", "organizer": "MédiaCom", "contact": "Nicolas Hocq", "is_internal": "False", "theme": "", "vulgarization": { "id": 1, "fr_label": "Tout public", "en_label": "General public" }, "registration": { "id": 1, "fr_label": "Sur inscription", "en_label": "Registration required" }, "keywords": "", "file": null, "icalendar_url": "https://memento.epfl.ch/event/export/121450/", "category": { "id": 1, "code": "CONF", "fr_label": "Conférences - Séminaires", "en_label": "Conferences - Seminars", "activated": true }, "academic_calendar_category": null, "domains": [], "mementos": [ "https://memento.epfl.ch/api/v1/mementos/1/?format=api", "https://memento.epfl.ch/api/v1/mementos/5/?format=api", "https://memento.epfl.ch/api/v1/mementos/6/?format=api", "https://memento.epfl.ch/api/v1/mementos/145/?format=api", "https://memento.epfl.ch/api/v1/mementos/389/?format=api", "https://memento.epfl.ch/api/v1/mementos/417/?format=api" ] }, { "id": 72646, "title": "AI Center x Sony AI Impact Talk Mireille El Gheche - Learning to Play at Human Speed: From Simulation to Expert-Level Robot Table Tennis", "slug": "ai-center-x-sony-ai-impact-talk-mireille-el-ghec-2", "event_url": "https://memento.epfl.ch/event/ai-center-x-sony-ai-impact-talk-mireille-el-ghec-2", "visual_url": "https://memento.epfl.ch/image/33898/200x112.jpg", "visual_large_url": "https://memento.epfl.ch/image/33898/720x405.jpg", "visual_maxsize_url": "https://memento.epfl.ch/image/33898/max-size.jpg", "lang": "en", "start_date": "2026-10-15", "end_date": "2026-10-15", "start_time": "10:15:00", "end_time": "11:15:00", "description": "<em><strong>Registration with an EPFL email is required: <a href=\"https://forms.cloud.microsoft/e/HbwUm7bFrd\">HERE</a>.</strong></em><br>\r\n<br>\r\n<u><strong>! This event is restricted to the EPFL community !</strong></u><br>\r\n<br>\r\n<strong>Title</strong><br>\r\nLearning to Play at Human Speed: From Simulation to Expert-Level Robot Table Tennis<br>\r\n<br>\r\n<strong>Abstract</strong><br>\r\nWhat does it take for a robot to compete with a human in one of the fastest and most dynamic sports?<br>\r\nTable tennis compresses many of the fundamental challenges of physical AI into just a few hundred milliseconds. The robot must perceive a ball travelling at high speed, estimate its position and spin, predict its trajectory, decide how to respond, and execute a precise motion, all while interacting with an intelligent and unpredictable opponent.<br>\r\nIn this talk, I will present Project ACE, an autonomous table tennis robot developed at Sony AI that progressed from learning basic racket skills to competing with elite human players. I will discuss the complete system behind this progression: high-speed visual perception, reinforcement learning, simulation, robot control, and the iterative sim-to-real process that enabled policies trained in simulation to perform on a real robot. Beyond table tennis, ACE provides a case study in what it takes to move from impressive robotic demonstrations to robust physical intelligence. I will share some of the lessons we learned about combining learning with control, using real-world failures to improve simulation, and designing AI systems that can adapt and act under the speed, uncertainty, and constraints of the physical world.<br>\r\n<br>\r\n<strong>Bio</strong><br>\r\nMireille El Gheche is a Lead Research Scientist at SoftBank Robotics, working at the intersection of artificial intelligence and robotics. Her expertise spans reinforcement learning, computer vision and perception, simulation, optimization, and real-world robotic systems, with a strong focus on translating research advances into robust physical systems.<br>\r\nPrior to joining SoftBank Robotics, Mireille was a Staff Research Scientist at Sony AI in Zurich, where she led research on Project ACE, an autonomous table tennis robot developed to compete with elite and professional human players. Before joining Sony AI, Mireille conducted academic research at EPFL and the University of Bordeaux, working across computer vision, and applied AI, including applications in medical AI. Her broader research interests lie in physical AI and intelligent robotic systems that can perceive, learn, adapt, and act in complex real-world environments.<br>\r\n ", "image_description": "", "creation_date": "2026-09-23T10:33:38", "last_modification_date": "2026-10-05T11:59:06", "link_label": "Registration required", "link_url": "https://forms.cloud.microsoft/e/HbwUm7bFrd", "canceled": "False", "cancel_reason": "", "place_and_room": "SG 0213", "url_place_and_room": "https://plan.epfl.ch/?room==SG%200213", "url_online_room": "https://epfl.zoom.us/j/63790840787?pwd=OHuE2cuqmmbEZ5yeZiGhkDpQpZqjLx.1", "spoken_languages": [ "https://memento.epfl.ch/api/v1/spoken_languages/2/?format=api" ], "speaker": "Dr. Mireille El Gheche", "organizer": "EPFL AI Center", "contact": "<a href=\"mailto:[email protected]\">Nicolas Machado</a>", "is_internal": "False", "theme": "", "vulgarization": { "id": 1, "fr_label": "Tout public", "en_label": "General public" }, "registration": { "id": 1, "fr_label": "Sur inscription", "en_label": "Registration required" }, "keywords": "AI, Robotics", "file": null, "icalendar_url": "https://memento.epfl.ch/event/export/121895/", "category": { "id": 1, "code": "CONF", "fr_label": "Conférences - Séminaires", "en_label": "Conferences - Seminars", "activated": true }, "academic_calendar_category": null, "domains": [], "mementos": [ "https://memento.epfl.ch/api/v1/mementos/1/?format=api", "https://memento.epfl.ch/api/v1/mementos/6/?format=api", "https://memento.epfl.ch/api/v1/mementos/8/?format=api", "https://memento.epfl.ch/api/v1/mementos/416/?format=api", "https://memento.epfl.ch/api/v1/mementos/417/?format=api" ] }, { "id": 72347, "title": "School Lecture Series: Thomas Friberg + Sophie Piticco, pool Architektur / EPFL Architecture", "slug": "school-lecture-series-thomas-friberg-sophie-piticc", "event_url": "https://memento.epfl.ch/event/school-lecture-series-thomas-friberg-sophie-piticc", "visual_url": "https://memento.epfl.ch/image/33607/200x112.jpg", "visual_large_url": "https://memento.epfl.ch/image/33607/720x405.jpg", "visual_maxsize_url": "https://memento.epfl.ch/image/33607/max-size.jpg", "lang": "en", "start_date": "2026-10-27", "end_date": "2026-10-27", "start_time": "18:30:00", "end_time": "20:00:00", "description": "<strong>Building for Disassembly<br>\r\nTemporary Sports Halls, Huts and a Hotel</strong><br>\r\nGrowing student numbers and the need to renovate numerous school facilities prompted the Canton of Zurich to seek a temporary solution for sports facilities. Each building is intended to remain at a given location between three to fifteen years, until it is either relocated or stored for future reassembly. pool Architektur responded by designing a prefabricated timber construction system that enables a variety of spatial configurations and appearances, allowing for careful integration into the surrounding environment. Other projects such as the room-within-a-room installation for “El Gato Muerto” or the temporary hotel “Momentum” have evolved as a result of pool’s building for disassembly.<br>\r\n<br>\r\n<strong>Thomas Friberg + Sophie Piticco, pool Architektur</strong><br>\r\npool Architektur evolved from a discussion platform for debates on architecture and urban planning and began its practical work as a collective in 1998. The office and its form are understood as a work in progress with regard to an ever-changing profession. The office has won numerous competitions and is primarily active in urban planning at different scales as well as residential, infrastructure and public building construction. Over the past decades, ideas and solutions have changed, as have names and faces, because diversity and change are at the heart of pool Architektur’s identity. <br>\r\n<br>\r\nThomas Friberg studied architecture at ETH Zurich. After graduating, he worked at ETH Studio Basel, David Chipperfield Architects, joining pool in 2008. In 2018 he was admitted as a new partner. <br>\r\n<br>\r\nSophie Piticco studied architecture at EPF Lausanne and ETH Zurich. After internships in Munich and Helsinki, she joined pool Architektur after graduating in 2017. Since 2023 she is an associate at the firm.<br>\r\n<br>\r\n<strong>Part of School Lecture Series, Autumn 2026, Learning Vol.1</strong><br>\r\nWe are told that learning is no longer confined to the school or the university, but it has become a continuous process that involves the totality of life. Yet in accepting this reality, we take for granted several questions that loom large within the contemporary idea of learning. In a time when technology and information are ubiquitous, does it still make sense that for learning to happen or be confined within a place? Is learning still an asymmetrical relationship where there are teachers and a student? And above all, is learning accessible, or has it become too expensive a commodity? In this lecture series, we’ll attempt to answer these questions by investigating learning on different levels such as technology, construction systems, educational spaces, and above all, making architecture. Indeed, the question that is more than anything else crucial to us is whether architecture is still a place of learning and not only of empowering those who have capital to build it. We will look at schools, drawings, robots, and measuring devices. We will ponder whether these things are only ‘tools’ to achieve a result or can still be vital places for learning. <br>\r\n<br>\r\n<strong>Recordings available on YouTube</strong><br>\r\n@epflarchitectureschool<br>\r\n<br>\r\n<strong>Graphic Design</strong><br>\r\nRoman Karrer & Sandi Gazic", "image_description": "", "creation_date": "2026-08-14T16:40:18", "last_modification_date": "2026-08-17T13:17:23", "link_label": "Poster School Lecture Series Fall 2026", "link_url": "https://go.epfl.ch/school-lecture-series-fall-2026", "canceled": "False", "cancel_reason": "", "place_and_room": "Foyer SG", "url_place_and_room": "https://plan.epfl.ch/?room=%3DSG%20294.22&dim_floor=2&lang=fr&dim_lang=fr&tree_groups=centres_nevralgiques_grp%2Cmobilite_acces_grp%2Crestauration_et_commerces_grp%2Censeignement%2Cservices_campus_grp%2Cequipements_grp&tree_group_layers_centres_nevralgiques_grp=&tree_group_layers_mobilite_acces_grp=metro&tree_group_layers_restauration_et_commerces_grp=&tree_group_layers_enseignement=guichet_etudiants&tree_group_layers_services_campus_grp=information_epfl&tree_group_layers_equipements_grp=&baselayer_ref=grp_backgrounds&map_x=2532923&map_y=1152547&map_zoom=12", "url_online_room": "", "spoken_languages": [ "https://memento.epfl.ch/api/v1/spoken_languages/2/?format=api" ], "speaker": "Thomas Friberg + Sophie Piticco, pool Architektur", "organizer": "<a href=\"http://[email protected]\" target=\"_blank\">EPFL Architecture</a>", "contact": "<a href=\"http://[email protected]\" target=\"_blank\">EPFL Architecture</a>", "is_internal": "False", "theme": "", "vulgarization": { "id": 1, "fr_label": "Tout public", "en_label": "General public" }, "registration": { "id": 3, "fr_label": "Entrée libre", "en_label": "Free" }, "keywords": "", "file": null, "icalendar_url": "https://memento.epfl.ch/event/export/121435/", "category": { "id": 1, "code": "CONF", "fr_label": "Conférences - Séminaires", "en_label": "Conferences - Seminars", "activated": true }, "academic_calendar_category": null, "domains": [], "mementos": [ "https://memento.epfl.ch/api/v1/mementos/4/?format=api", "https://memento.epfl.ch/api/v1/mementos/32/?format=api", "https://memento.epfl.ch/api/v1/mementos/417/?format=api" ] }, { "id": 72469, "title": "Trust, Sensing, and Learning for Provable Multi-Robot Performance", "slug": "trust-sensing-and-learning-for-provable-multi-robo", "event_url": "https://memento.epfl.ch/event/trust-sensing-and-learning-for-provable-multi-robo", "visual_url": "https://memento.epfl.ch/image/33717/200x112.jpg", "visual_large_url": "https://memento.epfl.ch/image/33717/720x405.jpg", "visual_maxsize_url": "https://memento.epfl.ch/image/33717/max-size.jpg", "lang": "en", "start_date": "2026-11-05", "end_date": "2026-11-05", "start_time": "11:00:00", "end_time": "12:00:00", "description": "<p>Multi-robot systems are physically embodied networks — they sense, move, and communicate through the physical world. The bar for safe decision-making rises as these systems enter safety-critical, real-world settings where they must perform well under uncertainty. Our work shows that physicality is a resource against the two kinds of uncertainty they face: intentional (or adversarial), where data is manipulated by malicious agents, and natural, where aspects of the environment are simply unknown. Most of this talk concerns intentional uncertainty. Here, one way to exploit physicality is by using communication as a sensor. Because the signals robots exchange are difficult to forge, they carry evidence that can be cross-validated to yield a quantifiable likelihood that an agent's data is trustworthy. This is the foundation of cy-trust, in which stochastic observations of trust model an agent's trustworthiness probabilistically from physical rather than cryptographic evidence. Each neighbor's contribution is then weighted by its trust value. Under this framework, we show that consensus, distributed optimization, and other core coordination tasks admit almost-sure convergence with bounded deviation from their nominal performance, even when malicious agents exceed half of a node's connectivity, past the classical Byzantine bound. We support this finding with both theory and hardware experiments under adversarial attack. Against natural uncertainty, we show that real-time sensing can be folded into rollout-based reinforcement learning, where the same machinery reweights futures rather than neighbors. We apply this idea to routing a fleet of robots to stochastically appearing demand and, with Project CETI, to the first autonomous robotic rendezvous with sperm whales at sea. Finally, we preview some of our future work combining trust with long-horizon sequential decision-making, targeting planning that stays provably resilient when the data informing the plan may itself be corrupted.<br>\r\n<br>\r\n<em>Stephanie Gil is the John L. Loeb Associate Professor of Engineering and Applied Sciences at Harvard University and an Associate Faculty member of the Kempner Institute. Her research focuses on trust and coordination in multi-robot systems, at the intersection of robotics, communication, and learning. Her contributions have been recognized through the DARPA Young Faculty Award (2024), the Office of Naval Research Young Investigator Award (2021), and the National Science Foundation CAREER Award (2019). She was named a 2020 Sloan Research Fellow for her work at the intersection of robotics and communication. She earned her Ph.D. at CSAIL at MIT, specializing in multi-robot coordination and control, and her B.S. at Cornell University.</em></p>", "image_description": "", "creation_date": "2026-08-31T09:19:27", "last_modification_date": "2026-09-03T18:05:52", "link_label": "", "link_url": "", "canceled": "False", "cancel_reason": "", "place_and_room": "MED 2 1124", "url_place_and_room": "https://plan.epfl.ch/?room==MED%202%201124", "url_online_room": "https://epfl.zoom.us/j/64474989189", "spoken_languages": [ "https://memento.epfl.ch/api/v1/spoken_languages/2/?format=api" ], "speaker": "<a href=\"https://www.linkedin.com/in/stephanie-gil/\">Stephanie Gil</a>", "organizer": "<a href=\"https://www.epfl.ch/research/domains/robotics/\">EPFL Robotics Center</a>", "contact": "<a href=\"https://people.epfl.ch/anca.rusu\">Anca Rusu</a>", "is_internal": "False", "theme": "", "vulgarization": { "id": 2, "fr_label": "Public averti", "en_label": "Informed public" }, "registration": { "id": 3, "fr_label": "Entrée libre", "en_label": "Free" }, "keywords": "", "file": null, "icalendar_url": "https://memento.epfl.ch/event/export/121626/", "category": { "id": 1, "code": "CONF", "fr_label": "Conférences - Séminaires", "en_label": "Conferences - Seminars", "activated": true }, "academic_calendar_category": null, "domains": [], "mementos": [ "https://memento.epfl.ch/api/v1/mementos/1/?format=api", "https://memento.epfl.ch/api/v1/mementos/6/?format=api", "https://memento.epfl.ch/api/v1/mementos/8/?format=api", "https://memento.epfl.ch/api/v1/mementos/417/?format=api" ] }, { "id": 72290, "title": "Technologies for Healthcare / ARCHIZOOM", "slug": "technologies-for-healthcare-archizoom", "event_url": "https://memento.epfl.ch/event/technologies-for-healthcare-archizoom", "visual_url": "https://memento.epfl.ch/image/33556/200x112.jpg", "visual_large_url": "https://memento.epfl.ch/image/33556/720x405.jpg", "visual_maxsize_url": "https://memento.epfl.ch/image/33556/max-size.jpg", "lang": "en", "start_date": "2026-11-07", "end_date": "2026-11-08", "start_time": "10:00:00", "end_time": "17:00:00", "description": "<strong>Saturday 7 & Sunday 8 November 2026</strong><br>\r\n<strong>10am-5pm –</strong> <strong>exhibition open continuously </strong><br>\r\n<br>\r\nOn the occasion of the next <a href=\"https://scientastic.epfl.ch/\">Scientastic</a> event, which takes place on the weekend of 7 and 8 November 2026 on the EPFL campus, with a focus on health technologies, Archizoom invites you to take part in a range of activities linked to the exhibition <a href=\"https://www.epfl.ch/campus/art-culture/museum-exhibitions/archizoom/do-robots-dream-of-construction-sites-2/\"><em>Do Robots Dream of Construction Sites? </em></a><br>\r\n<br>\r\n<strong><a href=\"https://forms.gle/8mG39FYernNXnsJG6\">GUIDED TOURS </a><br>\r\n11am / 4pm – </strong><strong><em>Do Robots Dream of Construction Sites? </em>in French</strong><br>\r\nCan we trust a robot on a building site? This guided tour explores what it means to build alongside increasingly capable machines, and how collaboration between humans and robots could affect our buildings, our trades and, by extension, our daily lives and health.<br>\r\n<br>\r\n<em><strong>SOCIAL CONTRACT 4.0, </strong></em><strong>MADELINE GANNON</strong><br>\r\n<strong>10am-5pm – an interactive robotic installation by the artist Madeline Gannon</strong><br>\r\nThe robots that build our world do exactly what they are told, when they are told, where they are told. But that relationship is ending: physical AI is giving our machines the intelligence to explore our world for themselves. What should they do with their newfound curiosity? This installation explores a new social contract with autonomous, intelligent systems (4.0) — one built on convincing, not controlling, machines. As you approach, the machine may choose to interact with you, or it may be too busy having fun on its own. It gets to decide. This work asks what it means to share a world with technology whose trust we may need to earn first.", "image_description": "", "creation_date": "2026-08-03T09:25:54", "last_modification_date": "2026-08-03T09:25:56", "link_label": "Plus d'informations", "link_url": "https://www.epfl.ch/campus/art-culture/museum-exhibitions/archizoom/fr/scientastic-2/", "canceled": "False", "cancel_reason": "", "place_and_room": "Archizoom", "url_place_and_room": "https://plan.epfl.ch/?room==SG%201212", "url_online_room": "", "spoken_languages": [ "https://memento.epfl.ch/api/v1/spoken_languages/1/?format=api", "https://memento.epfl.ch/api/v1/spoken_languages/2/?format=api" ], "speaker": "Madeline Gannon", "organizer": "Archizoom, Scientastic", "contact": "Cyril Veillon, Solène Hoffmann", "is_internal": "False", "theme": "", "vulgarization": { "id": 1, "fr_label": "Tout public", "en_label": "General public" }, "registration": { "id": 3, "fr_label": "Entrée libre", "en_label": "Free" }, "keywords": "architecture, science, techonology, health, robots, robotics, durability", "file": null, "icalendar_url": "https://memento.epfl.ch/event/export/121351/", "category": { "id": 9, "code": "MANIF", "fr_label": "Événements festifs et culturels", "en_label": "Cultural events", "activated": true }, "academic_calendar_category": null, "domains": [], "mementos": [ "https://memento.epfl.ch/api/v1/mementos/1/?format=api", "https://memento.epfl.ch/api/v1/mementos/4/?format=api", "https://memento.epfl.ch/api/v1/mementos/6/?format=api", "https://memento.epfl.ch/api/v1/mementos/8/?format=api", "https://memento.epfl.ch/api/v1/mementos/21/?format=api", "https://memento.epfl.ch/api/v1/mementos/22/?format=api", "https://memento.epfl.ch/api/v1/mementos/32/?format=api", "https://memento.epfl.ch/api/v1/mementos/45/?format=api", "https://memento.epfl.ch/api/v1/mementos/145/?format=api", "https://memento.epfl.ch/api/v1/mementos/417/?format=api" ] }, { "id": 72281, "title": "Do Robots Dream of Construction Sites? / ARCHIZOOM x CRCL", "slug": "do-robots-dream-of-construction-sites-archizoom--6", "event_url": "https://memento.epfl.ch/event/do-robots-dream-of-construction-sites-archizoom--6", "visual_url": "https://memento.epfl.ch/image/33549/200x112.jpg", "visual_large_url": "https://memento.epfl.ch/image/33549/720x405.jpg", "visual_maxsize_url": "https://memento.epfl.ch/image/33549/max-size.jpg", "lang": "en", "start_date": "2026-11-24", "end_date": "2026-11-24", "start_time": "17:30:00", "end_time": "18:15:00", "description": "<strong>Tuesday 24 November</strong><br>\r\n<strong>5.30pm –</strong> Guided tour of the exhibition by Stefana Parascho, director of the CRCL – Lab for Creative Computation at EPFL<br>\r\n<strong>6.30pm –</strong> Followed by the opening of the exhibition <em>The Extraction of Value</em> with Paolo Tombesi<br>\r\n<br>\r\nWhat if robots didn’t replace us, but worked alongside us? Robots are capable of assembling, analysing, experimenting and learning from their mistakes. Could they take on construction work without replacing human labour? Research carried out by the CRCL explores a form of collaboration between humans and machines that departs from the traditional promise of automation. It opens the way to more inclusive building sites and non-standardised, more environmentally friendly architecture that goes beyond the mere logic of replacement and productivity. <br>\r\n<br>\r\nCan we trust a robot on a building site? This guided tour explores what it means to build alongside increasingly capable machines, and how collaboration between humans and robots could affect our buildings, our trades and, by extension, our daily lives.<br>\r\n<br>\r\n<em>Robots in operation during guided tours !</em>", "image_description": "", "creation_date": "2026-07-27T16:15:08", "last_modification_date": "2026-07-27T16:16:15", "link_label": "Inscription", "link_url": "https://forms.gle/8mG39FYernNXnsJG6", "canceled": "False", "cancel_reason": "", "place_and_room": "Archizoom", "url_place_and_room": "https://plan.epfl.ch/?room==SG%201212", "url_online_room": "", "spoken_languages": [ "https://memento.epfl.ch/api/v1/spoken_languages/2/?format=api" ], "speaker": "Stefana Parascho", "organizer": "Archizoom ", "contact": "Cyril Veillon, Solène Hoffmann", "is_internal": "False", "theme": "", "vulgarization": { "id": 1, "fr_label": "Tout public", "en_label": "General public" }, "registration": { "id": 3, "fr_label": "Entrée libre", "en_label": "Free" }, "keywords": "Architecture, Technology, Construction, Robotic, Robots, Travail, Labor, Durability", "file": null, "icalendar_url": "https://memento.epfl.ch/event/export/121335/", "category": { "id": 9, "code": "MANIF", "fr_label": "Événements festifs et culturels", "en_label": "Cultural events", "activated": true }, "academic_calendar_category": null, "domains": [], "mementos": [ "https://memento.epfl.ch/api/v1/mementos/1/?format=api", "https://memento.epfl.ch/api/v1/mementos/4/?format=api", "https://memento.epfl.ch/api/v1/mementos/6/?format=api", "https://memento.epfl.ch/api/v1/mementos/8/?format=api", "https://memento.epfl.ch/api/v1/mementos/21/?format=api", "https://memento.epfl.ch/api/v1/mementos/22/?format=api", "https://memento.epfl.ch/api/v1/mementos/32/?format=api", "https://memento.epfl.ch/api/v1/mementos/45/?format=api", "https://memento.epfl.ch/api/v1/mementos/145/?format=api", "https://memento.epfl.ch/api/v1/mementos/417/?format=api" ] } ] }