Event List
retrieve:
Return the details about the given Event id.
list:
List all Event objects.
GET /api/v1/events/?format=api&offset=100&ordering=event__end_time
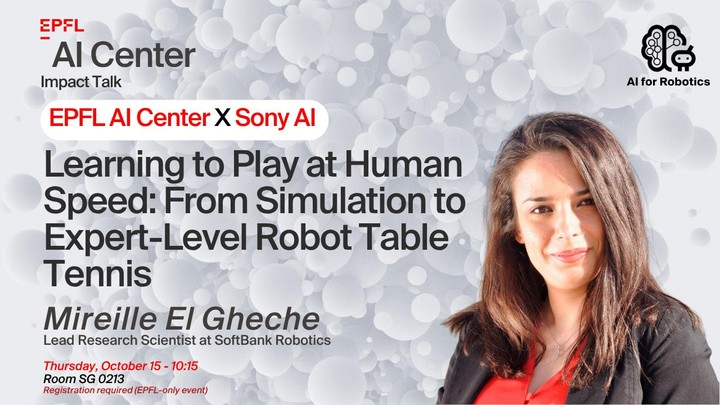
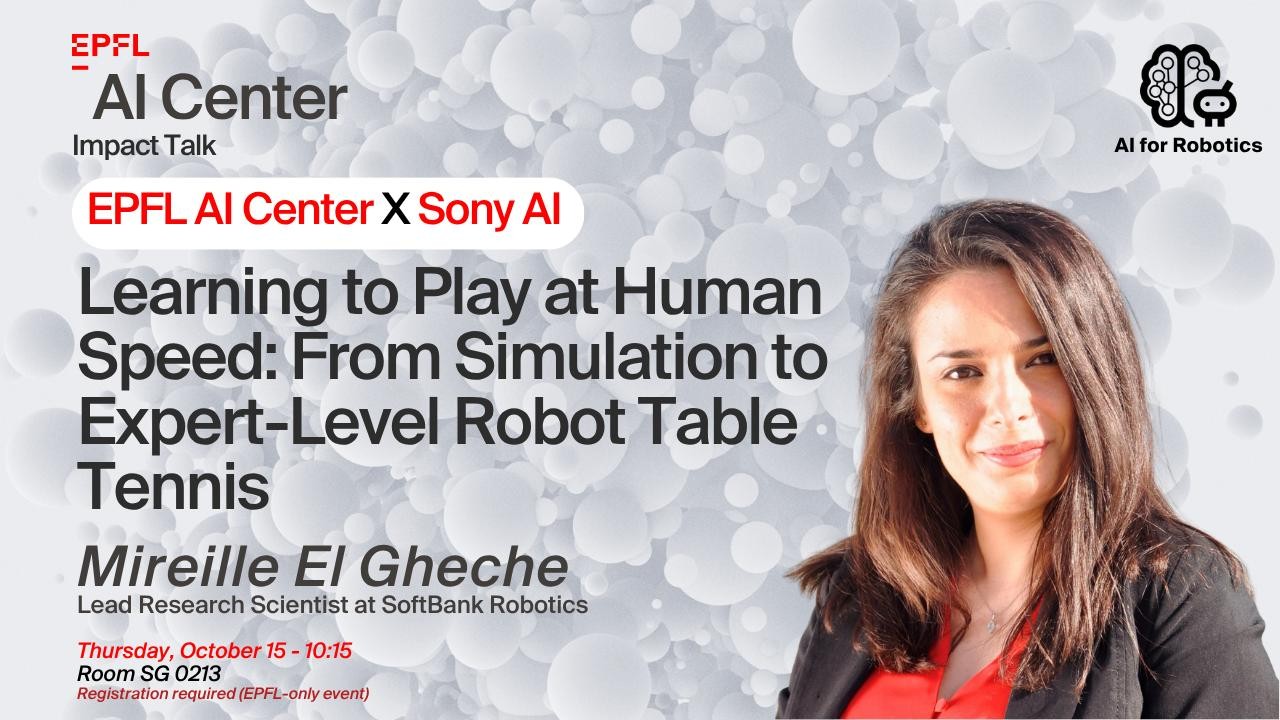
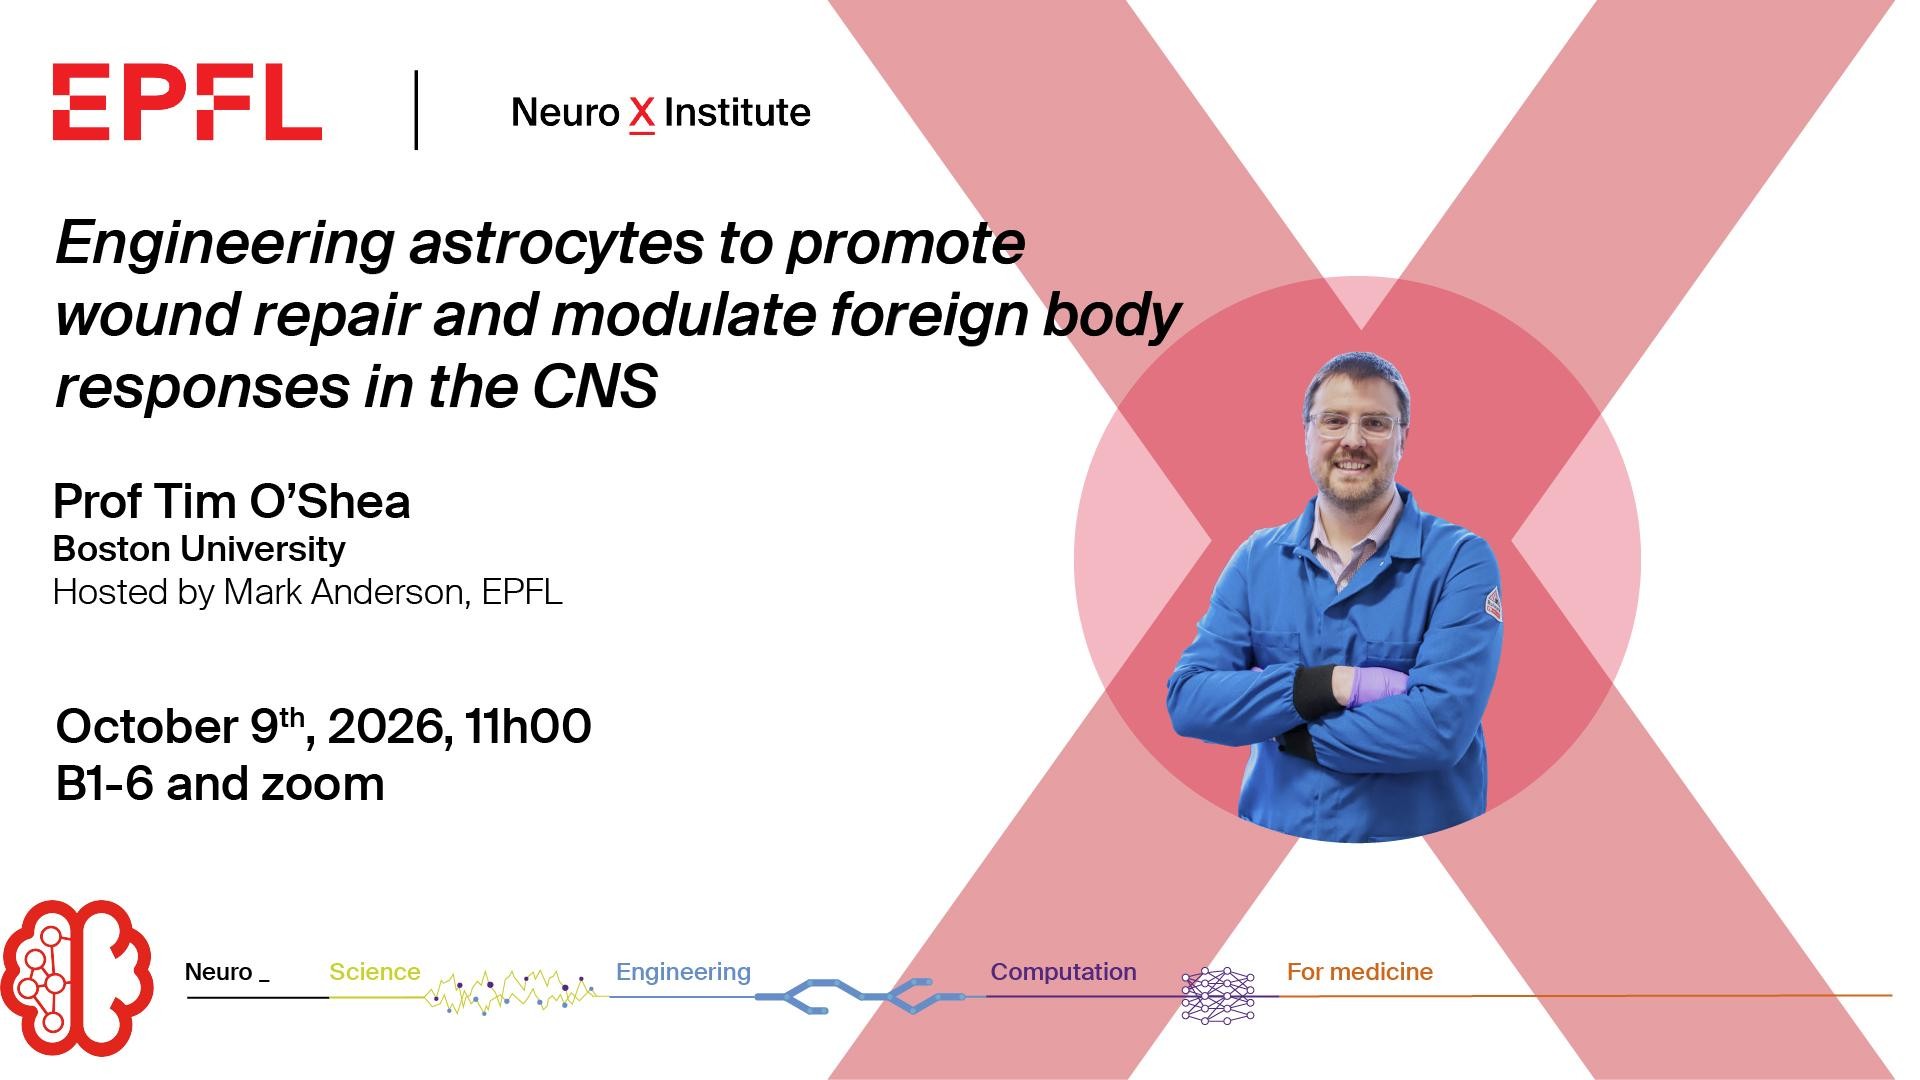
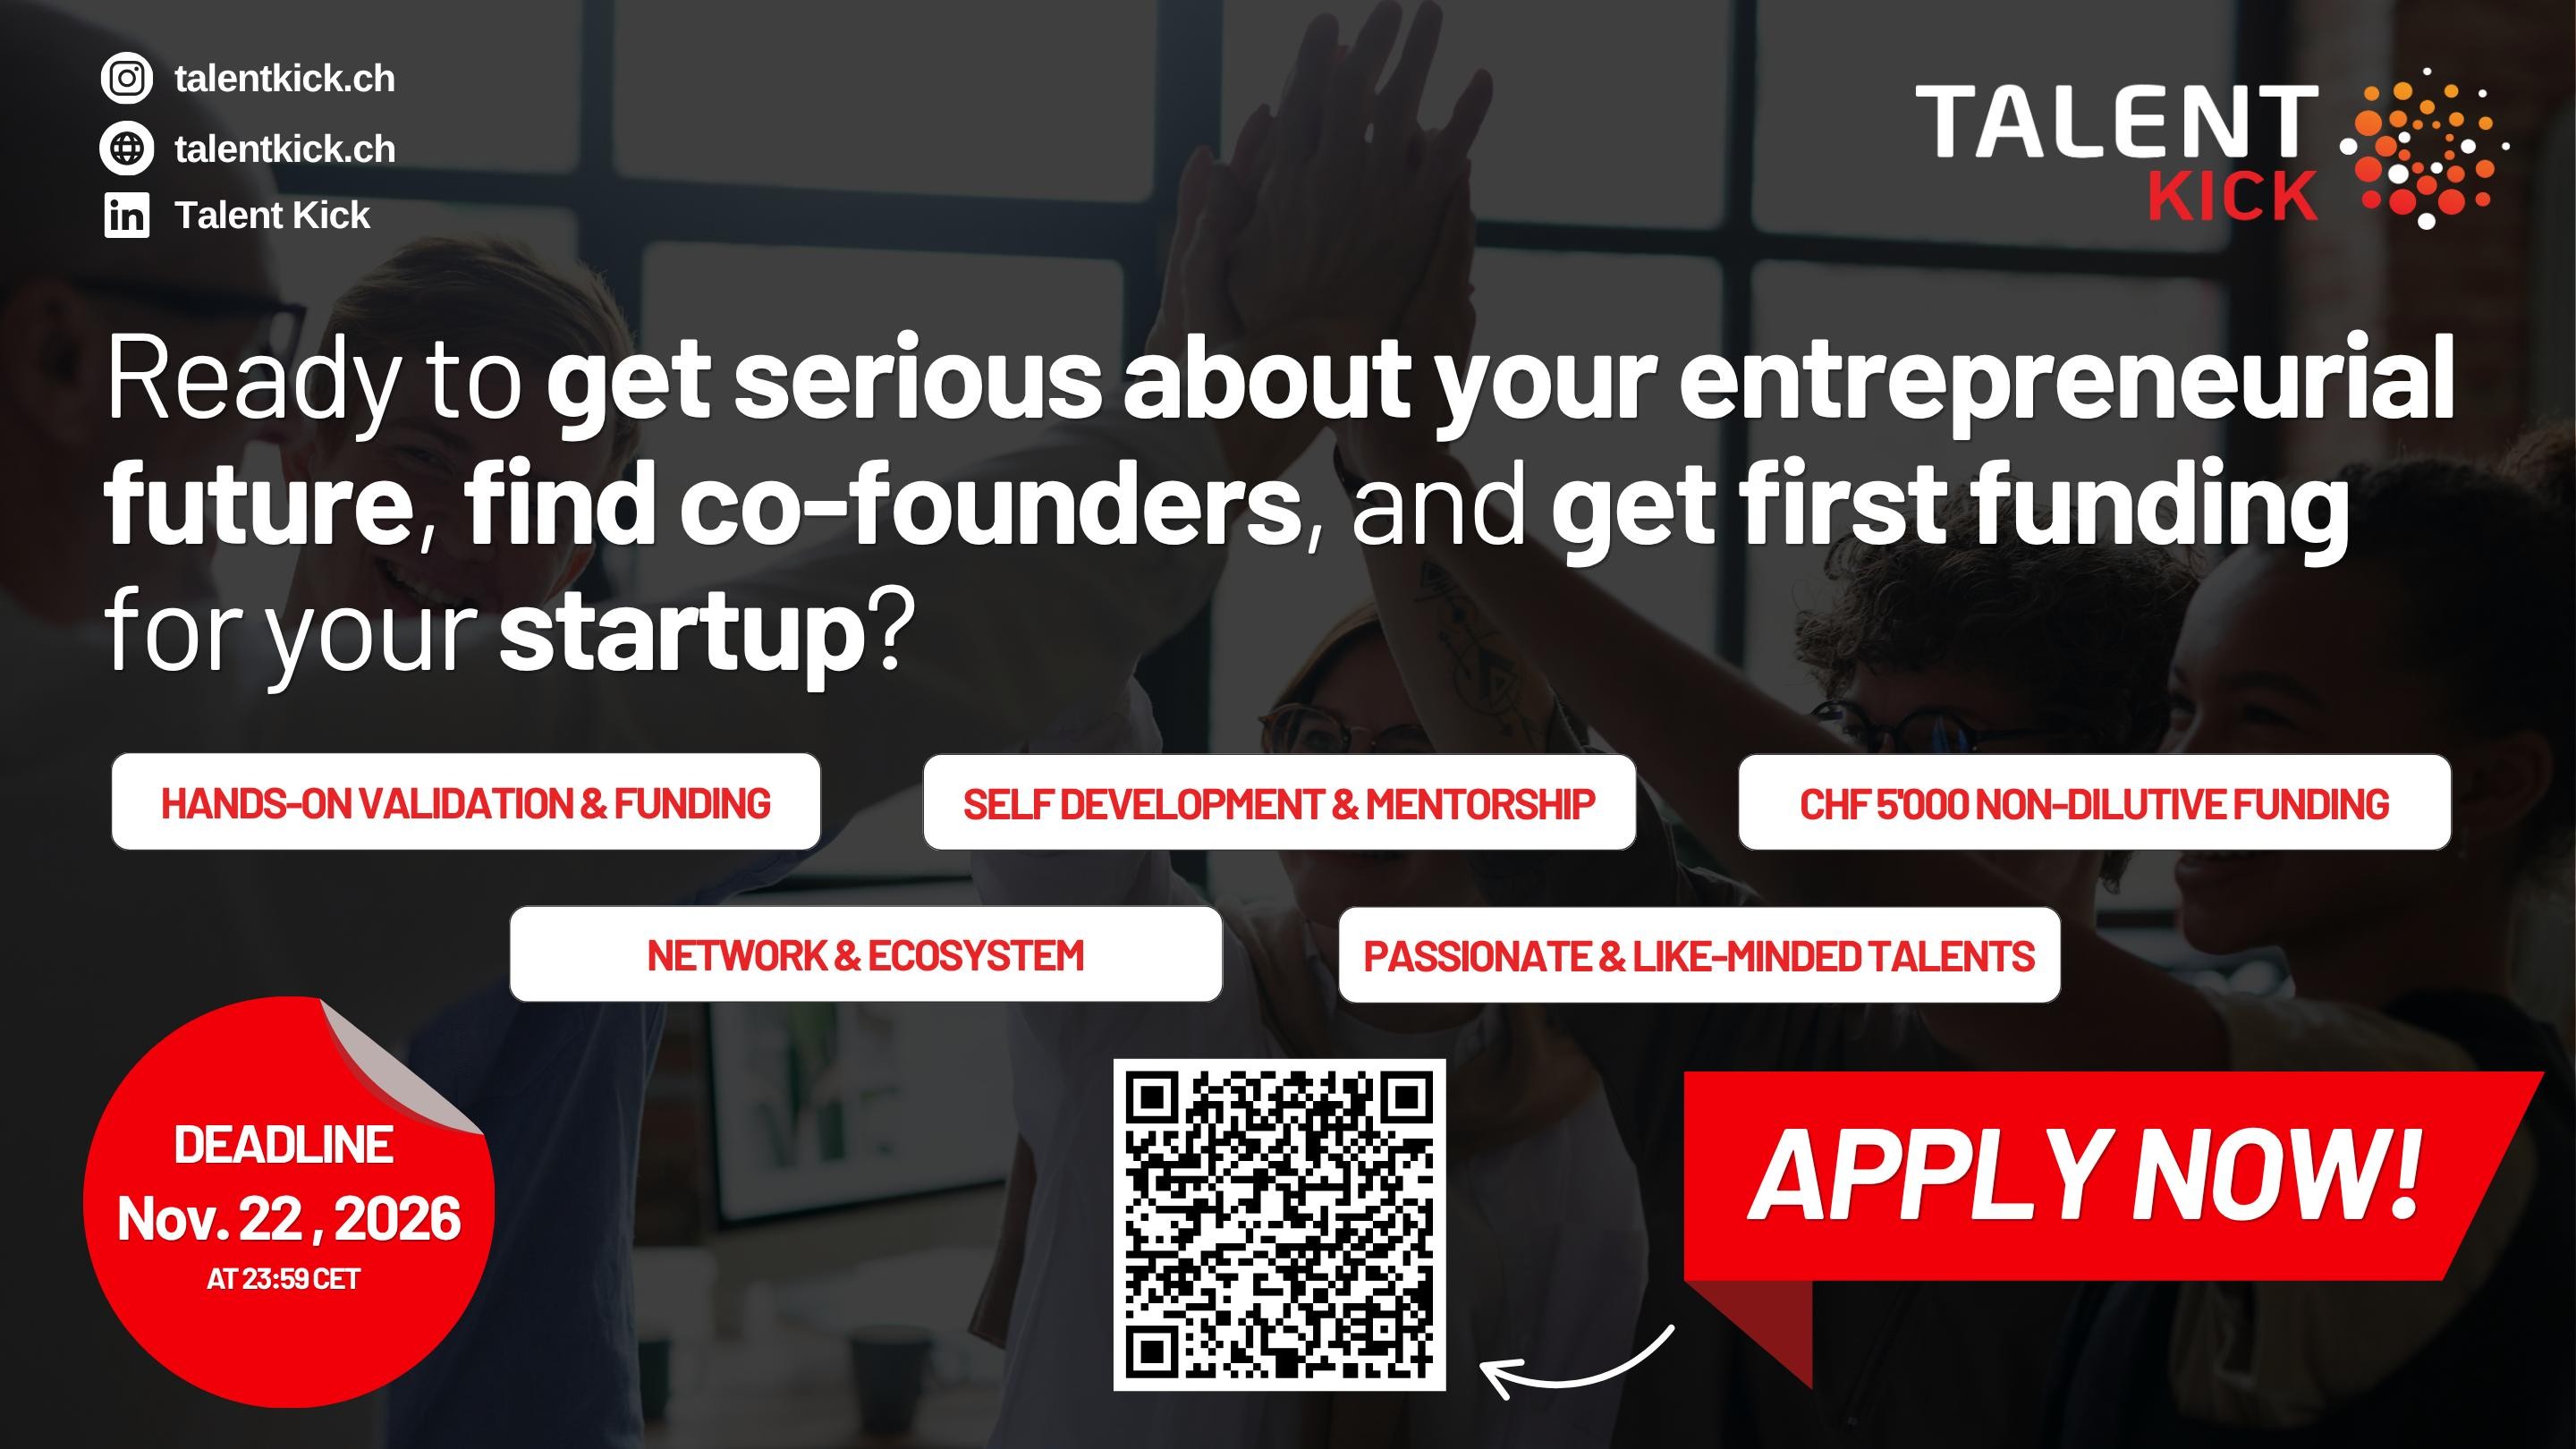
{ "count": 266, "next": "https://memento.epfl.ch/api/v1/events/?format=api&limit=10&offset=110&ordering=event__end_time", "previous": "https://memento.epfl.ch/api/v1/events/?format=api&limit=10&offset=90&ordering=event__end_time", "results": [ { "id": 72646, "title": "AI Center x Sony AI Impact Talk Mireille El Gheche - Learning to Play at Human Speed: From Simulation to Expert-Level Robot Table Tennis", "slug": "ai-center-x-sony-ai-impact-talk-mireille-el-ghec-2", "event_url": "https://memento.epfl.ch/event/ai-center-x-sony-ai-impact-talk-mireille-el-ghec-2", "visual_url": "https://memento.epfl.ch/image/33898/200x112.jpg", "visual_large_url": "https://memento.epfl.ch/image/33898/720x405.jpg", "visual_maxsize_url": "https://memento.epfl.ch/image/33898/max-size.jpg", "lang": "en", "start_date": "2026-10-15", "end_date": "2026-10-15", "start_time": "10:15:00", "end_time": "11:15:00", "description": "<em><strong>Registration with an EPFL email is required: <a href=\"https://forms.cloud.microsoft/e/HbwUm7bFrd\">HERE</a>.</strong></em><br>\r\n<br>\r\n<u><strong>! This event is restricted to the EPFL community !</strong></u><br>\r\n<br>\r\n<strong>Title</strong><br>\r\nLearning to Play at Human Speed: From Simulation to Expert-Level Robot Table Tennis<br>\r\n<br>\r\n<strong>Abstract</strong><br>\r\nWhat does it take for a robot to compete with a human in one of the fastest and most dynamic sports?<br>\r\nTable tennis compresses many of the fundamental challenges of physical AI into just a few hundred milliseconds. The robot must perceive a ball travelling at high speed, estimate its position and spin, predict its trajectory, decide how to respond, and execute a precise motion, all while interacting with an intelligent and unpredictable opponent.<br>\r\nIn this talk, I will present Project ACE, an autonomous table tennis robot developed at Sony AI that progressed from learning basic racket skills to competing with elite human players. I will discuss the complete system behind this progression: high-speed visual perception, reinforcement learning, simulation, robot control, and the iterative sim-to-real process that enabled policies trained in simulation to perform on a real robot. Beyond table tennis, ACE provides a case study in what it takes to move from impressive robotic demonstrations to robust physical intelligence. I will share some of the lessons we learned about combining learning with control, using real-world failures to improve simulation, and designing AI systems that can adapt and act under the speed, uncertainty, and constraints of the physical world.<br>\r\n<br>\r\n<strong>Bio</strong><br>\r\nMireille El Gheche is a Lead Research Scientist at SoftBank Robotics, working at the intersection of artificial intelligence and robotics. Her expertise spans reinforcement learning, computer vision and perception, simulation, optimization, and real-world robotic systems, with a strong focus on translating research advances into robust physical systems.<br>\r\nPrior to joining SoftBank Robotics, Mireille was a Staff Research Scientist at Sony AI in Zurich, where she led research on Project ACE, an autonomous table tennis robot developed to compete with elite and professional human players. Before joining Sony AI, Mireille conducted academic research at EPFL and the University of Bordeaux, working across computer vision, and applied AI, including applications in medical AI. Her broader research interests lie in physical AI and intelligent robotic systems that can perceive, learn, adapt, and act in complex real-world environments.<br>\r\n ", "image_description": "", "creation_date": "2026-09-23T10:33:38", "last_modification_date": "2026-10-05T11:59:06", "link_label": "Registration required", "link_url": "https://forms.cloud.microsoft/e/HbwUm7bFrd", "canceled": "False", "cancel_reason": "", "place_and_room": "SG 0213", "url_place_and_room": "https://plan.epfl.ch/?room==SG%200213", "url_online_room": "https://epfl.zoom.us/j/63790840787?pwd=OHuE2cuqmmbEZ5yeZiGhkDpQpZqjLx.1", "spoken_languages": [ "https://memento.epfl.ch/api/v1/spoken_languages/2/?format=api" ], "speaker": "Dr. Mireille El Gheche", "organizer": "EPFL AI Center", "contact": "<a href=\"mailto:[email protected]\">Nicolas Machado</a>", "is_internal": "False", "theme": "", "vulgarization": { "id": 1, "fr_label": "Tout public", "en_label": "General public" }, "registration": { "id": 1, "fr_label": "Sur inscription", "en_label": "Registration required" }, "keywords": "AI, Robotics", "file": null, "icalendar_url": "https://memento.epfl.ch/event/export/121895/", "category": { "id": 1, "code": "CONF", "fr_label": "Conférences - Séminaires", "en_label": "Conferences - Seminars", "activated": true }, "academic_calendar_category": null, "domains": [], "mementos": [ "https://memento.epfl.ch/api/v1/mementos/1/?format=api", "https://memento.epfl.ch/api/v1/mementos/6/?format=api", "https://memento.epfl.ch/api/v1/mementos/8/?format=api", "https://memento.epfl.ch/api/v1/mementos/416/?format=api", "https://memento.epfl.ch/api/v1/mementos/417/?format=api" ] }, { "id": 71001, "title": "Gestion de projet européen - Projets ERC et MSCA", "slug": "gestion-de-projet-europeen-projets-erc-et-msca-2", "event_url": "https://memento.epfl.ch/event/gestion-de-projet-europeen-projets-erc-et-msca-2", "visual_url": "https://memento.epfl.ch/image/32389/200x112.jpg", "visual_large_url": "https://memento.epfl.ch/image/32389/720x405.jpg", "visual_maxsize_url": "https://memento.epfl.ch/image/32389/max-size.jpg", "lang": "en", "start_date": "2026-11-26", "end_date": "2026-11-26", "start_time": "09:30:00", "end_time": "12:00:00", "description": "<p>Programmes-cadres européens de la recherche et de l’innovation.<br>\r\n<br>\r\nVotre laboratoire participe à un ou plusieurs projets européens et une de vos missions est d’en assurer une gestion efficace au niveaux administratif, financier et celui des ressources humaines ? Pour cela, il est important de prendre le temps de vous familiariser avec la structure de ces projets et avec certaines règles de gestion qui leurs sont spécifiques.<br>\r\n<br>\r\nCette formation vous propose de prendre connaissance des documents contractuels et de leur contenu qui est utile pour votre gestion. Les règles de gestion administrative, financière et RH seront présentées et discutées en se basant sur des cas pratiques.<br>\r\nLa formation permettra aussi aux participants de se familiariser avec le portail européen et la plateforme de reporting du SEFRI.<br>\r\n<br>\r\nIl est recommandé de suivre cette formation le plus tôt possible, idéalement vers le commencement du projet.</p>", "image_description": "", "creation_date": "2026-01-30T10:11:14", "last_modification_date": "2026-01-30T10:12:40", "link_label": "Inscription", "link_url": "https://epfl.eu.crossknowledge.com/site/m/public_training/565", "canceled": "False", "cancel_reason": "", "place_and_room": "", "url_place_and_room": "", "url_online_room": "", "spoken_languages": [ "https://memento.epfl.ch/api/v1/spoken_languages/1/?format=api" ], "speaker": "EU-Funding Team of the Research Office", "organizer": "KeepLearning", "contact": "[email protected]", "is_internal": "True", "theme": "", "vulgarization": { "id": 1, "fr_label": "Tout public", "en_label": "General public" }, "registration": { "id": 1, "fr_label": "Sur inscription", "en_label": "Registration required" }, "keywords": "", "file": null, "icalendar_url": "https://memento.epfl.ch/event/export/119525/", "category": { "id": 15, "code": "FORM", "fr_label": "Formations internes", "en_label": "Internal trainings", "activated": true }, "academic_calendar_category": null, "domains": [], "mementos": [ "https://memento.epfl.ch/api/v1/mementos/145/?format=api", "https://memento.epfl.ch/api/v1/mementos/431/?format=api", "https://memento.epfl.ch/api/v1/mementos/6/?format=api" ] }, { "id": 72194, "title": "Neuro-X seminar: Prof Tim O'Shea - Engineering astrocytes to promote wound repair and modulate foreign body responses in the CNS", "slug": "neuro-x-seminar-prof-tim-o-shea-engineering-astroc", "event_url": "https://memento.epfl.ch/event/neuro-x-seminar-prof-tim-o-shea-engineering-astroc", "visual_url": "https://memento.epfl.ch/image/33474/200x112.jpg", "visual_large_url": "https://memento.epfl.ch/image/33474/720x405.jpg", "visual_maxsize_url": "https://memento.epfl.ch/image/33474/max-size.jpg", "lang": "en", "start_date": "2026-10-09", "end_date": "2026-10-09", "start_time": "11:00:00", "end_time": "12:00:00", "description": "<p>Astrocytes are the predominant glial cells in the mammalian central nervous system (CNS) and play essential roles in maintaining neural circuit activity and tissue homeostasis. In response to CNS insult, including traumatic injury or implantation of a medical device, astrocytes undergo a conserved, temporally regulated reprogramming that reshapes their prioritized functions to protect adjacent neural tissue. The nature and extent of astrocyte reprogramming critically influences outcomes after CNS insult. For example, regeneration after traumatic CNS injury in adult mammals is limited by local responding astrocytes lacking sufficient self-renewal capacity. By contrast, the CNS of neonate (newborn) mammals possesses exceptional parenchymal repair capacity owing to immature astrocytes with elevated proliferative and migratory potential. In the context of an implanted medical device, the spatial extent of astrocyte reprogramming and how impacted astrocytes respond to any further device micromotion, latent infection, or other persistent device-derived stimuli, dictates device performance and longevity. Engineering astrocyte responses to promote targeted functional gains while preserving key capabilities of healthy neural tissue astrocytes will be critical to enabling effective neural regeneration therapies and improving long-term performance of implanted devices. In this talk, I will outline our emerging understanding of how adult astrocytes adaptively reprogram in response to CNS injury and implanted foreign bodies, drawing insights from innovative astrocyte-specific transcriptomic bioassays. I will also provide an overview of biomaterial and cell-grafting strategies that we are exploring to direct astrocyte responses in preclinical models of stroke, spinal cord injury, and foreign body responses.<br>\r\n<br>\r\n<strong>Bio:</strong><br>\r\n<strong>Dr. Timothy O’Shea, PhD</strong> is an Assistant Professor in the Biomedical Engineering department at Boston University (BU). Tim grew up in Brisbane, Australia and completed a Bachelor of Medical Engineering (First Class Honours) and a Masters in Engineering Management at Queensland University of Technology (QUT) before moving to the US for graduate school. He completed his PhD study in Medical Engineering and Medical Physics within the collaborative Health Sciences and Technology program of the Harvard Medical School and the Massachusetts Institute of Technology where we conducted PhD thesis research with Institute Professor Robert Langer. As a Postdoctoral Fellow in Neurobiology at UCLA, he worked with Professors Michael Sofroniew (Neurobiology) and Timothy Deming (Bioengineering) developing and testing novel bioengineering tools to study biological mechanisms involved in CNS injury and repair as well as the CNS foreign body response to implants. Since Fall 2020 he has been leading the Glia Engineering Lab at BU where he has received numerous awards including the Maximizing Investigators' Research Award (MIRA) from NIH and grants from several spinal cord injury research foundations such as Craig H Neilsen, Paralyzed Veterans of America, Bryon Reisch, and Wings for Life.</p>", "image_description": "", "creation_date": "2026-07-01T12:06:17", "last_modification_date": "2026-09-29T15:26:49", "link_label": "", "link_url": "", "canceled": "False", "cancel_reason": "", "place_and_room": "B1-6", "url_place_and_room": "https://plan.epfl.ch/?room==B1%206%20272.043", "url_online_room": "https://epfl.zoom.us/j/62394730036?pwd=jz0K4NPrEtbqswaGBRIOJ0Kf64PwYm.1", "spoken_languages": [ "https://memento.epfl.ch/api/v1/spoken_languages/2/?format=api" ], "speaker": "<a href=\"https://www.bu.edu/eng/profile/timothy-oshea-ph-d/\">Tim O'Shea</a>", "organizer": "<a href=\"http://people.epfl.ch/mark.anderson\">Mark Anderson</a>", "contact": "<a href=\"https://people.epfl.ch/niels.lion?lang=en\">Niels Lion</a>", "is_internal": "False", "theme": "", "vulgarization": { "id": 2, "fr_label": "Public averti", "en_label": "Informed public" }, "registration": { "id": 3, "fr_label": "Entrée libre", "en_label": "Free" }, "keywords": "", "file": null, "icalendar_url": "https://memento.epfl.ch/event/export/121206/", "category": { "id": 1, "code": "CONF", "fr_label": "Conférences - Séminaires", "en_label": "Conferences - Seminars", "activated": true }, "academic_calendar_category": null, "domains": [], "mementos": [ "https://memento.epfl.ch/api/v1/mementos/19/?format=api", "https://memento.epfl.ch/api/v1/mementos/111/?format=api", "https://memento.epfl.ch/api/v1/mementos/392/?format=api" ] }, { "id": 72342, "title": "Dynamics in Brain-inspired Neural Networks // 2-6 November 2026", "slug": "dynamics-in-brain-inspired-neural-networks-2-6-nov", "event_url": "https://memento.epfl.ch/event/dynamics-in-brain-inspired-neural-networks-2-6-nov", "visual_url": null, "visual_large_url": null, "visual_maxsize_url": null, "lang": "en", "start_date": "2026-11-02", "end_date": "2026-11-06", "start_time": "13:30:00", "end_time": "12:00:00", "description": "<p>The brain forms a large recurrent spiking neural network with extremely high connectivity making time-dependent mean-field approaches valuable tools to translate the microscopic level of single-neuron dynamics to the mesoscopic or macroscopic level. In recent years, experimental data as well as simulation studies have highlighted the importance of low-dimensional macroscopic dynamics in large recurrent spiking networks. On the theory side, the notion of low-rank connectivity has shifted into the focus of interest. <br>\r\nThis meeting will to bring together researchers in mathematical and theoretical neuroscience who address the above topics from different perspectives. <br>\r\n<br>\r\n<strong>Phase 1</strong><br>\r\nPublic lectures from Monday afternoon – Wednesday end of day<br>\r\n<br>\r\nPresentations will alternate between speakers with a physics and those with a math background so as to foster links between the two communities.<br>\r\n<br>\r\n<strong>Phase 2</strong><br>\r\nTutorials for PhD students on Thursday and Friday. </p>", "image_description": "", "creation_date": "2026-08-14T10:16:34", "last_modification_date": "2026-08-14T10:20:36", "link_label": "Event website", "link_url": "https://www.epfl.ch/labs/lcn/dynamics-in-brain-inspired-neural-networks-2-6-november-2026/", "canceled": "False", "cancel_reason": "", "place_and_room": "", "url_place_and_room": "", "url_online_room": "", "spoken_languages": [], "speaker": "", "organizer": "", "contact": "[email protected]", "is_internal": "False", "theme": "", "vulgarization": { "id": 2, "fr_label": "Public averti", "en_label": "Informed public" }, "registration": { "id": 1, "fr_label": "Sur inscription", "en_label": "Registration required" }, "keywords": "", "file": null, "icalendar_url": "https://memento.epfl.ch/event/export/121429/", "category": { "id": 1, "code": "CONF", "fr_label": "Conférences - Séminaires", "en_label": "Conferences - Seminars", "activated": true }, "academic_calendar_category": null, "domains": [], "mementos": [ "https://memento.epfl.ch/api/v1/mementos/43/?format=api", "https://memento.epfl.ch/api/v1/mementos/260/?format=api" ] }, { "id": 72398, "title": "Training \"Smart Publishing\"", "slug": "training-smart-publishing-7", "event_url": "https://memento.epfl.ch/event/training-smart-publishing-7", "visual_url": "https://memento.epfl.ch/image/33649/200x112.jpg", "visual_large_url": "https://memento.epfl.ch/image/33649/720x405.jpg", "visual_maxsize_url": "https://memento.epfl.ch/image/33649/max-size.jpg", "lang": "en", "start_date": "2026-11-17", "end_date": "2026-11-17", "start_time": "10:00:00", "end_time": "12:00:00", "description": "<div class=\"all_text\"><strong>Publishing to make your research available to the scientific community is a rewarding step. Do you want to understand how it works and know some tips that will help at the submission stage?</strong><br>\r\n<br>\r\nIn this workshop we will address the publication process in the current context:</div>\r\n\r\n<ul>\r\n\t<li>Become familiar with the context of scholarly communication and its latest developments.</li>\r\n\t<li>Understand the important steps leading to publication, including peer-review.</li>\r\n\t<li>Ensure your compliance towards EPFL and funders' Open Access policy.</li>\r\n\t<li>Know and protect your rights as an author according to EPFL’s policy.</li>\r\n\t<li>Get to understand what a publishing contract entails.</li>\r\n</ul>\r\n\r\n<div class=\"all_text\"><br>\r\n<a href=\"https://bookwhen.com/fr/epfl_library/e/ev-s5o9y-20261117100000\">Registration</a><br>\r\n<br>\r\nMore information about <a href=\"https://www.epfl.ch/campus/library/training/\">EPFL Library Training offer</a></div>", "image_description": "CC-BY-NC-SA EPFL Library", "creation_date": "2026-08-20T10:22:40", "last_modification_date": "2026-08-20T15:51:07", "link_label": "Registration", "link_url": "https://bookwhen.com/fr/epfl_library/e/ev-s5o9y-20261117100000", "canceled": "False", "cancel_reason": "", "place_and_room": "ELG 116", "url_place_and_room": "https://plan.epfl.ch/?room==ELG%20116", "url_online_room": "", "spoken_languages": [ "https://memento.epfl.ch/api/v1/spoken_languages/2/?format=api" ], "speaker": "EPFL Library Training Team", "organizer": "EPFL Library", "contact": "[email protected]", "is_internal": "False", "theme": "", "vulgarization": { "id": 1, "fr_label": "Tout public", "en_label": "General public" }, "registration": { "id": 1, "fr_label": "Sur inscription", "en_label": "Registration required" }, "keywords": "", "file": null, "icalendar_url": "https://memento.epfl.ch/event/export/121520/", "category": { "id": 15, "code": "FORM", "fr_label": "Formations internes", "en_label": "Internal trainings", "activated": true }, "academic_calendar_category": null, "domains": [], "mementos": [ "https://memento.epfl.ch/api/v1/mementos/1/?format=api", "https://memento.epfl.ch/api/v1/mementos/3/?format=api", "https://memento.epfl.ch/api/v1/mementos/5/?format=api", "https://memento.epfl.ch/api/v1/mementos/6/?format=api", "https://memento.epfl.ch/api/v1/mementos/8/?format=api", "https://memento.epfl.ch/api/v1/mementos/269/?format=api", "https://memento.epfl.ch/api/v1/mementos/275/?format=api" ] }, { "id": 72469, "title": "Trust, Sensing, and Learning for Provable Multi-Robot Performance", "slug": "trust-sensing-and-learning-for-provable-multi-robo", "event_url": "https://memento.epfl.ch/event/trust-sensing-and-learning-for-provable-multi-robo", "visual_url": "https://memento.epfl.ch/image/33717/200x112.jpg", "visual_large_url": "https://memento.epfl.ch/image/33717/720x405.jpg", "visual_maxsize_url": "https://memento.epfl.ch/image/33717/max-size.jpg", "lang": "en", "start_date": "2026-11-05", "end_date": "2026-11-05", "start_time": "11:00:00", "end_time": "12:00:00", "description": "<p>Multi-robot systems are physically embodied networks — they sense, move, and communicate through the physical world. The bar for safe decision-making rises as these systems enter safety-critical, real-world settings where they must perform well under uncertainty. Our work shows that physicality is a resource against the two kinds of uncertainty they face: intentional (or adversarial), where data is manipulated by malicious agents, and natural, where aspects of the environment are simply unknown. Most of this talk concerns intentional uncertainty. Here, one way to exploit physicality is by using communication as a sensor. Because the signals robots exchange are difficult to forge, they carry evidence that can be cross-validated to yield a quantifiable likelihood that an agent's data is trustworthy. This is the foundation of cy-trust, in which stochastic observations of trust model an agent's trustworthiness probabilistically from physical rather than cryptographic evidence. Each neighbor's contribution is then weighted by its trust value. Under this framework, we show that consensus, distributed optimization, and other core coordination tasks admit almost-sure convergence with bounded deviation from their nominal performance, even when malicious agents exceed half of a node's connectivity, past the classical Byzantine bound. We support this finding with both theory and hardware experiments under adversarial attack. Against natural uncertainty, we show that real-time sensing can be folded into rollout-based reinforcement learning, where the same machinery reweights futures rather than neighbors. We apply this idea to routing a fleet of robots to stochastically appearing demand and, with Project CETI, to the first autonomous robotic rendezvous with sperm whales at sea. Finally, we preview some of our future work combining trust with long-horizon sequential decision-making, targeting planning that stays provably resilient when the data informing the plan may itself be corrupted.<br>\r\n<br>\r\n<em>Stephanie Gil is the John L. Loeb Associate Professor of Engineering and Applied Sciences at Harvard University and an Associate Faculty member of the Kempner Institute. Her research focuses on trust and coordination in multi-robot systems, at the intersection of robotics, communication, and learning. Her contributions have been recognized through the DARPA Young Faculty Award (2024), the Office of Naval Research Young Investigator Award (2021), and the National Science Foundation CAREER Award (2019). She was named a 2020 Sloan Research Fellow for her work at the intersection of robotics and communication. She earned her Ph.D. at CSAIL at MIT, specializing in multi-robot coordination and control, and her B.S. at Cornell University.</em></p>", "image_description": "", "creation_date": "2026-08-31T09:19:27", "last_modification_date": "2026-09-03T18:05:52", "link_label": "", "link_url": "", "canceled": "False", "cancel_reason": "", "place_and_room": "MED 2 1124", "url_place_and_room": "https://plan.epfl.ch/?room==MED%202%201124", "url_online_room": "https://epfl.zoom.us/j/64474989189", "spoken_languages": [ "https://memento.epfl.ch/api/v1/spoken_languages/2/?format=api" ], "speaker": "<a href=\"https://www.linkedin.com/in/stephanie-gil/\">Stephanie Gil</a>", "organizer": "<a href=\"https://www.epfl.ch/research/domains/robotics/\">EPFL Robotics Center</a>", "contact": "<a href=\"https://people.epfl.ch/anca.rusu\">Anca Rusu</a>", "is_internal": "False", "theme": "", "vulgarization": { "id": 2, "fr_label": "Public averti", "en_label": "Informed public" }, "registration": { "id": 3, "fr_label": "Entrée libre", "en_label": "Free" }, "keywords": "", "file": null, "icalendar_url": "https://memento.epfl.ch/event/export/121626/", "category": { "id": 1, "code": "CONF", "fr_label": "Conférences - Séminaires", "en_label": "Conferences - Seminars", "activated": true }, "academic_calendar_category": null, "domains": [], "mementos": [ "https://memento.epfl.ch/api/v1/mementos/1/?format=api", "https://memento.epfl.ch/api/v1/mementos/6/?format=api", "https://memento.epfl.ch/api/v1/mementos/8/?format=api", "https://memento.epfl.ch/api/v1/mementos/417/?format=api" ] }, { "id": 72636, "title": "H∞boys and INDIans: Can they work together for flight control?", "slug": "hboys-and-indians-can-they-work-together-for-fligh", "event_url": "https://memento.epfl.ch/event/hboys-and-indians-can-they-work-together-for-fligh", "visual_url": "https://memento.epfl.ch/image/33880/200x112.jpg", "visual_large_url": "https://memento.epfl.ch/image/33880/720x405.jpg", "visual_maxsize_url": "https://memento.epfl.ch/image/33880/max-size.jpg", "lang": "en", "start_date": "2026-10-07", "end_date": "2026-10-07", "start_time": "11:00:00", "end_time": "12:00:00", "description": "<strong>Abstract</strong><br>\r\nSince the early days of aircraft autopilots, flight control law design has been dominated by gain scheduling: a family of linear controllers designed at trim points across the flight envelope and interpolated as the aerospace vehicle's operating condition changes. The approach is reliable and well understood, but it is also labor-intensive, requiring extensive linearization, controller interpolation, and lengthy re-tuning whenever the airframe or mission profile changes while its classical stability and performance guarantees hold only under restrictive assumptions.<br>\r\n<br>\r\n(Incremental) Nonlinear Dynamic Inversion — (I)NDI — emerged as an attractive alternative, first as full-state NDI in the 1980s–90s and later, in its incremental form, replacing much (though not all) of the reliance on an accurate onboard model with direct sensor feedback of angular acceleration. The result is a simple, largely envelope-independent control structure that (almost) eliminates the scheduling and interpolation burden. The price, however, is the loss of the a priori robustness guarantees that gain-scheduled designs, however cumbersome, were built to provide. Robust control theory, born in the same timeframe as NDI, offers exactly those guarantees, but has traditionally lived in a separate, frequency-domain world from INDI's incremental, time-domain philosophy.<br>\r\n<br>\r\nThis talk shows how the two could be brought closer or even work together. We present hybrid INDI architectures combining a sensor-based and a model-based inversion core and paired with an outer loop tuned via structured synthesis therefore combining the advantages of both worlds. We then generalize this bridge through a formal duality between (I)NDI and quasi-LPV control, unifying robust analysis and synthesis across both worlds and clarifying exactly where INDI's modularity is paid for in achievable robustness. These results are validated across various aerospace applications such as aircraft, space launchers and drones.<br>\r\n<br>\r\n<strong>Biography</strong><br>\r\n<br>\r\nDr. Spilios Theodoulis is an associate professor in the Aerospace GNC cluster within the Control & Simulation (C&S) section, at the Faculty of Aerospace Engineering (AE) of the Delft University of Technology (TU Delft). Before joining TU Delft, he spent fourteen years at the French-German Research Institute of Saint-Louis (ISL), where he was Deputy Head of the GNC department. He is the founder of the Aerospace dynamics and RObust Control (AEROCON) research group along with its advanced projects branch—the ∞-Lab, and also an adjunct professor at the University of Strasbourg, University of Paris-Saclay and Cranfield University teaching tensor-based flight dynamics and automatic (flight) control. He has been involved in the research and development of both civilian and defense projects with EU government agencies, industry and academia in the field of GNC for more than 20 years.<br>\r\n<br>\r\nHis research interests focus on two complementary fields. First, <em>modeling and flight dynamics</em> of complex aerospace systems, including uncertainty modeling and linear/nonlinear-parameter-varying dynamics. Second, (multivariable) <em>stability and</em> <em>control</em> systems spanning from robust/nonlinear control and analysis to control theory-inspired guidance algorithms. The algorithms developed are showcased in several classes of systems (including the facilities of the AE C&S section such as SIMONA, PH-LAB, etc.) such as civil and fighter aircraft, rotorcraft, drones, hypersonic vehicles, space launchers, as well as guided systems. He maintains active collaborations with leading research institutes, including ONERA, DLR, NLR, TNO, NASA, and ESA-ESTEC; academic partners such as ISAE-SUPAERO, Cranfield University, and NYU Abu Dhabi; and industrial partners including Dassault Aviation, Airbus Defence & Space, MBDA, Indra Deimos, PLD Space, Lockheed Martin Skunk Works, and others.<br>\r\n<br>\r\nHe is an Associate Fellow of the American Institute of Aeronautics and Astronautics (Class of 2023), co-recipient of both <em>1-Star</em> and <em>2-Star Innovation Awards</em> (2019) from MBDA, and his students have received (some) distinctions, including the best PhD award in the area of systems and control from the University of Strasbourg (2017). He also serves on various technical committees (AIAA GNC, IFAC Aerospace, CEAS GNC) as well as on the organizing and program conference committees related to the field of GNC (AIAA SciTech, IFAC WC/ACA, EuroGNC, etc.).<br>\r\n<br>\r\nHis most daunting challenge to date though, remains the robust stabilization of his two young daughters Iris and Hera, who are constantly reminding him that nature is neither linear nor time-invariant.<br>\r\n<br>\r\n<br>\r\n ", "image_description": "", "creation_date": "2026-09-22T11:05:26", "last_modification_date": "2026-09-22T16:45:19", "link_label": "", "link_url": "", "canceled": "False", "cancel_reason": "", "place_and_room": "ME C2 405", "url_place_and_room": "https://plan.epfl.ch/?room==ME%20C2%20405", "url_online_room": "", "spoken_languages": [ "https://memento.epfl.ch/api/v1/spoken_languages/2/?format=api" ], "speaker": "<a href=\"https://www.tudelft.nl/en/staff/s.theodoulis/\">Dr. Spilios Theodoulis, associate professor in the Aerospace GNC cluster within the Control & Simulation (C&S) section, at the Faculty of Aerospace Engineering (AE) of the Delft University of Technology (TUDelft), Netherlands</a>", "organizer": "Professor <a href=\"https://people.epfl.ch/alireza.karimi\">Alireza Karimi</a>", "contact": "[email protected]", "is_internal": "False", "theme": "", "vulgarization": { "id": 1, "fr_label": "Tout public", "en_label": "General public" }, "registration": { "id": 3, "fr_label": "Entrée libre", "en_label": "Free" }, "keywords": "", "file": null, "icalendar_url": "https://memento.epfl.ch/event/export/121878/", "category": { "id": 1, "code": "CONF", "fr_label": "Conférences - Séminaires", "en_label": "Conferences - Seminars", "activated": true }, "academic_calendar_category": null, "domains": [], "mementos": [ "https://memento.epfl.ch/api/v1/mementos/8/?format=api", "https://memento.epfl.ch/api/v1/mementos/15/?format=api" ] }, { "id": 72674, "title": "Talent Kick - Build your startup while studying", "slug": "talent-kick-build-your-startup-while-studying", "event_url": "https://memento.epfl.ch/event/talent-kick-build-your-startup-while-studying", "visual_url": "https://memento.epfl.ch/image/33900/200x112.jpg", "visual_large_url": "https://memento.epfl.ch/image/33900/720x405.jpg", "visual_maxsize_url": "https://memento.epfl.ch/image/33900/max-size.jpg", "lang": "en", "start_date": "2026-11-22", "end_date": "2026-11-22", "start_time": "11:00:00", "end_time": "12:00:00", "description": "<p>Are you a student or researcher interested in entrepreneurship? Whether you already have a technology or problem you want to explore, are looking for co-founders, or simply want to discover what building a startup could look like, Talent Kick can help you take the next step.<br>\r\n<br>\r\n<a href=\"https://www.talentkick.ch/\">Talent Kick</a> is a free, cross-university entrepreneurship program that supports students and researchers in exploring promising ideas and technologies, finding co-founders and developing a startup alongside their studies.<br>\r\n<br>\r\nParticipants can benefit from:\r\n</p><ul>\r\n\t<li>up to CHF 5,000 in non-dilutive funding to test and validate their ideas</li>\r\n\t<li>support to find co-founders with complementary skills</li>\r\n\t<li>individual leadership coaching and expert mentorship</li>\r\n\t<li>connections to Switzerland's entrepreneurship and startup ecosystem</li>\r\n</ul>\r\n<strong>Spring 2027 applications</strong><br>\r\n<br>\r\nApplications for the Spring 2027 batch are open until <strong>22 November 2026</strong>. <a href=\"https://www.talentkick.ch/apply?utm_campaign=tk_s27_partners&utm_source=email&utm_medium=link\">Learn more and apply</a><br>\r\n<br>\r\n<strong>Discover Talent Kick at Immersion Day</strong><br>\r\n<br>\r\nCurious about the program before applying? Talent Kick Immersion Day on 14 October 2026 in Zurich brings together students, researchers, founders, alumni and members of the community for a day of founder stories, discussions and networking. Application deadline: <strong>27 September 2026. </strong><a href=\"https://www.talentkick.ch/immersionday2026?utm_campaign=tk_s27_partners&utm_source=email&utm_medium=link\">Learn more about Immersion Day</a>", "image_description": "", "creation_date": "2026-09-25T07:44:50", "last_modification_date": "2026-09-25T07:45:20", "link_label": "Talent Kick", "link_url": "https://www.talentkick.ch/", "canceled": "False", "cancel_reason": "", "place_and_room": "", "url_place_and_room": "", "url_online_room": "", "spoken_languages": [ "https://memento.epfl.ch/api/v1/spoken_languages/2/?format=api" ], "speaker": "", "organizer": "<a href=\"https://www.talentkick.ch/\">Talent Kick</a>", "contact": "<a href=\"mailto:[email protected]\">Cécila Molina</a>", "is_internal": "False", "theme": "", "vulgarization": { "id": 2, "fr_label": "Public averti", "en_label": "Informed public" }, "registration": { "id": 3, "fr_label": "Entrée libre", "en_label": "Free" }, "keywords": "startup; entrepreneurship", "file": null, "icalendar_url": "https://memento.epfl.ch/event/export/121927/", "category": { "id": 16, "code": "PROP", "fr_label": "Appel à proposition", "en_label": "Call for proposal", "activated": true }, "academic_calendar_category": null, "domains": [], "mementos": [ "https://memento.epfl.ch/api/v1/mementos/3/?format=api", "https://memento.epfl.ch/api/v1/mementos/119/?format=api", "https://memento.epfl.ch/api/v1/mementos/422/?format=api" ] }, { "id": 72724, "title": "Designing Social Robots with Older Adults: Context, Adaptation, and Dignity", "slug": "designing-social-robots-with-older-adults-context", "event_url": "https://memento.epfl.ch/event/designing-social-robots-with-older-adults-context", "visual_url": "https://memento.epfl.ch/image/33940/200x112.jpg", "visual_large_url": "https://memento.epfl.ch/image/33940/720x405.jpg", "visual_maxsize_url": "https://memento.epfl.ch/image/33940/max-size.jpg", "lang": "en", "start_date": "2026-11-11", "end_date": "2026-11-11", "start_time": "11:00:00", "end_time": "12:00:00", "description": "<p>How social robots look, behave, and offer support should reflect the people and environments they encounter. Drawing on studies with older adults in rural Indiana and urban Houston, this talk examines how individual needs, preferences, everyday surroundings, and care relationships can inform the physical forms and interaction styles of future social robots.<br>\r\n<br>\r\nThrough participatory design, observations, and interviews, I center older adults’ perspectives on meaningful support, acceptable interaction, and personal boundaries. Encounters with robot companions have brought moments of enjoyment, surprise, and support, while revealing challenges involving communication, expectations, privacy, and control. I explore how embodiment, movement, voice, and interaction pacing shape these experiences, and how caregivers can support engagement while preserving older adults’ choices and dignity.<br>\r\n<br>\r\nThese findings inform design requirements for robots that people can understand, guide, and adjust as their circumstances change. I connect them to opportunities for adaptive robot behavior, accessible interaction, and shared control, including how robots might recognize when assistance is welcome and make their actions easier to interpret or interrupt. The talk positions older adults as active contributors to robotics research, whose lived expertise can shape both future robot companions and the broader systems of support surrounding them.<br>\r\n<br>\r\n<br>\r\n<strong>Biography</strong><br>\r\nChorong Park, Ph.D., is an Assistant Professor and Presidential Frontier Faculty at the University of Houston’s Gerald D. Hines College of Architecture and Design, where she leads the Empathetic Lifespan AI & Robotics for Aging (ELARA) Lab. Her research connects human–robot interaction, human-centered AI, and participatory design to develop social robots and supportive technologies with older adults and caregivers.<br>\r\n<br>\r\nDrawing on studies in rural Indiana and urban Houston, she investigates how robots’ physical forms and interactions can fit older adults’ needs, surroundings, and everyday lives. Her work centers older adults’ perspectives on companionship, support, privacy, personal boundaries, and dignity, including how caregiver involvement can preserve individual choice and control.<br>\r\n<br>\r\nHer research is informed by more than 500 hours of volunteer technology support with older adults and people with disabilities and has appeared at ACM CHI, ACM ASSETS, and IEEE robotics venues. She earned her Ph.D. in Technology, with a graduate minor in Gerontology, and her master’s degree in UX Design from Purdue University.<br>\r\n<br>\r\n<u>Further information</u>:<br>\r\nUniversity of Houston research feature<br>\r\n(<a href=\"https://stories.uh.edu/2026-ai-robots-for-older-adults/index.html\">https://stories.uh.edu/2026-ai-robots-for-older-adults/index.html</a>)<br>\r\nELARA Lab website<br>\r\n(<a href=\"https://elaralab.org/\">https://elaralab.org</a>/)<br>\r\n </p>", "image_description": "", "creation_date": "2026-09-30T16:15:15", "last_modification_date": "2026-09-30T16:25:59", "link_label": "", "link_url": "", "canceled": "False", "cancel_reason": "", "place_and_room": "ME A3 31", "url_place_and_room": "https://plan.epfl.ch/?room==ME%20A3%2031", "url_online_room": "https://epfl.zoom.us/j/69492652047", "spoken_languages": [ "https://memento.epfl.ch/api/v1/spoken_languages/2/?format=api" ], "speaker": "<a href=\"https://elaralab.org/\">Prof. Chorong Park</a>", "organizer": "<a href=\"https://www.epfl.ch/research/domains/robotics/\">Robotics Center</a>", "contact": "<a href=\"https://people.epfl.ch/anca.rusu?lang=en\">Anca Rusu</a>", "is_internal": "False", "theme": "", "vulgarization": { "id": 2, "fr_label": "Public averti", "en_label": "Informed public" }, "registration": { "id": 3, "fr_label": "Entrée libre", "en_label": "Free" }, "keywords": "", "file": null, "icalendar_url": "https://memento.epfl.ch/event/export/122004/", "category": { "id": 1, "code": "CONF", "fr_label": "Conférences - Séminaires", "en_label": "Conferences - Seminars", "activated": true }, "academic_calendar_category": null, "domains": [], "mementos": [ "https://memento.epfl.ch/api/v1/mementos/1/?format=api", "https://memento.epfl.ch/api/v1/mementos/6/?format=api", "https://memento.epfl.ch/api/v1/mementos/8/?format=api", "https://memento.epfl.ch/api/v1/mementos/416/?format=api" ] }, { "id": 72023, "title": "Seminar in Finance", "slug": "seminar-in-finance-30", "event_url": "https://memento.epfl.ch/event/seminar-in-finance-30", "visual_url": "https://memento.epfl.ch/image/33316/200x112.jpg", "visual_large_url": "https://memento.epfl.ch/image/33316/720x405.jpg", "visual_maxsize_url": "https://memento.epfl.ch/image/33316/max-size.jpg", "lang": "en", "start_date": "2026-10-30", "end_date": "2026-10-30", "start_time": "11:00:00", "end_time": "12:15:00", "description": "", "image_description": "", "creation_date": "2026-06-03T15:10:00", "last_modification_date": "2026-06-03T16:52:30", "link_label": "", "link_url": "", "canceled": "False", "cancel_reason": "", "place_and_room": "UNIL, Extranef, room 126", "url_place_and_room": "", "url_online_room": "", "spoken_languages": [ "https://memento.epfl.ch/api/v1/spoken_languages/2/?format=api" ], "speaker": "<a href=\"https://www.edhec.edu/en/research-and-faculty/faculty/professors-and-researchers/raman-uppal\">Raman Uppal - EDHEC</a>", "organizer": "", "contact": "[email protected]", "is_internal": "False", "theme": "", "vulgarization": { "id": 2, "fr_label": "Public averti", "en_label": "Informed public" }, "registration": { "id": 3, "fr_label": "Entrée libre", "en_label": "Free" }, "keywords": "", "file": null, "icalendar_url": "https://memento.epfl.ch/event/export/120963/", "category": { "id": 1, "code": "CONF", "fr_label": "Conférences - Séminaires", "en_label": "Conferences - Seminars", "activated": true }, "academic_calendar_category": null, "domains": [], "mementos": [ "https://memento.epfl.ch/api/v1/mementos/112/?format=api", "https://memento.epfl.ch/api/v1/mementos/3/?format=api", "https://memento.epfl.ch/api/v1/mementos/116/?format=api", "https://memento.epfl.ch/api/v1/mementos/105/?format=api" ] } ] }