Event List
retrieve:
Return the details about the given Event id.
list:
List all Event objects.
GET /api/v1/events/?format=api&offset=110&ordering=event__start_time
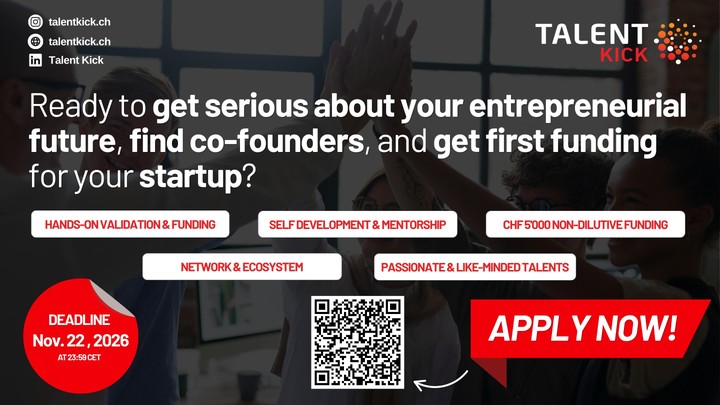
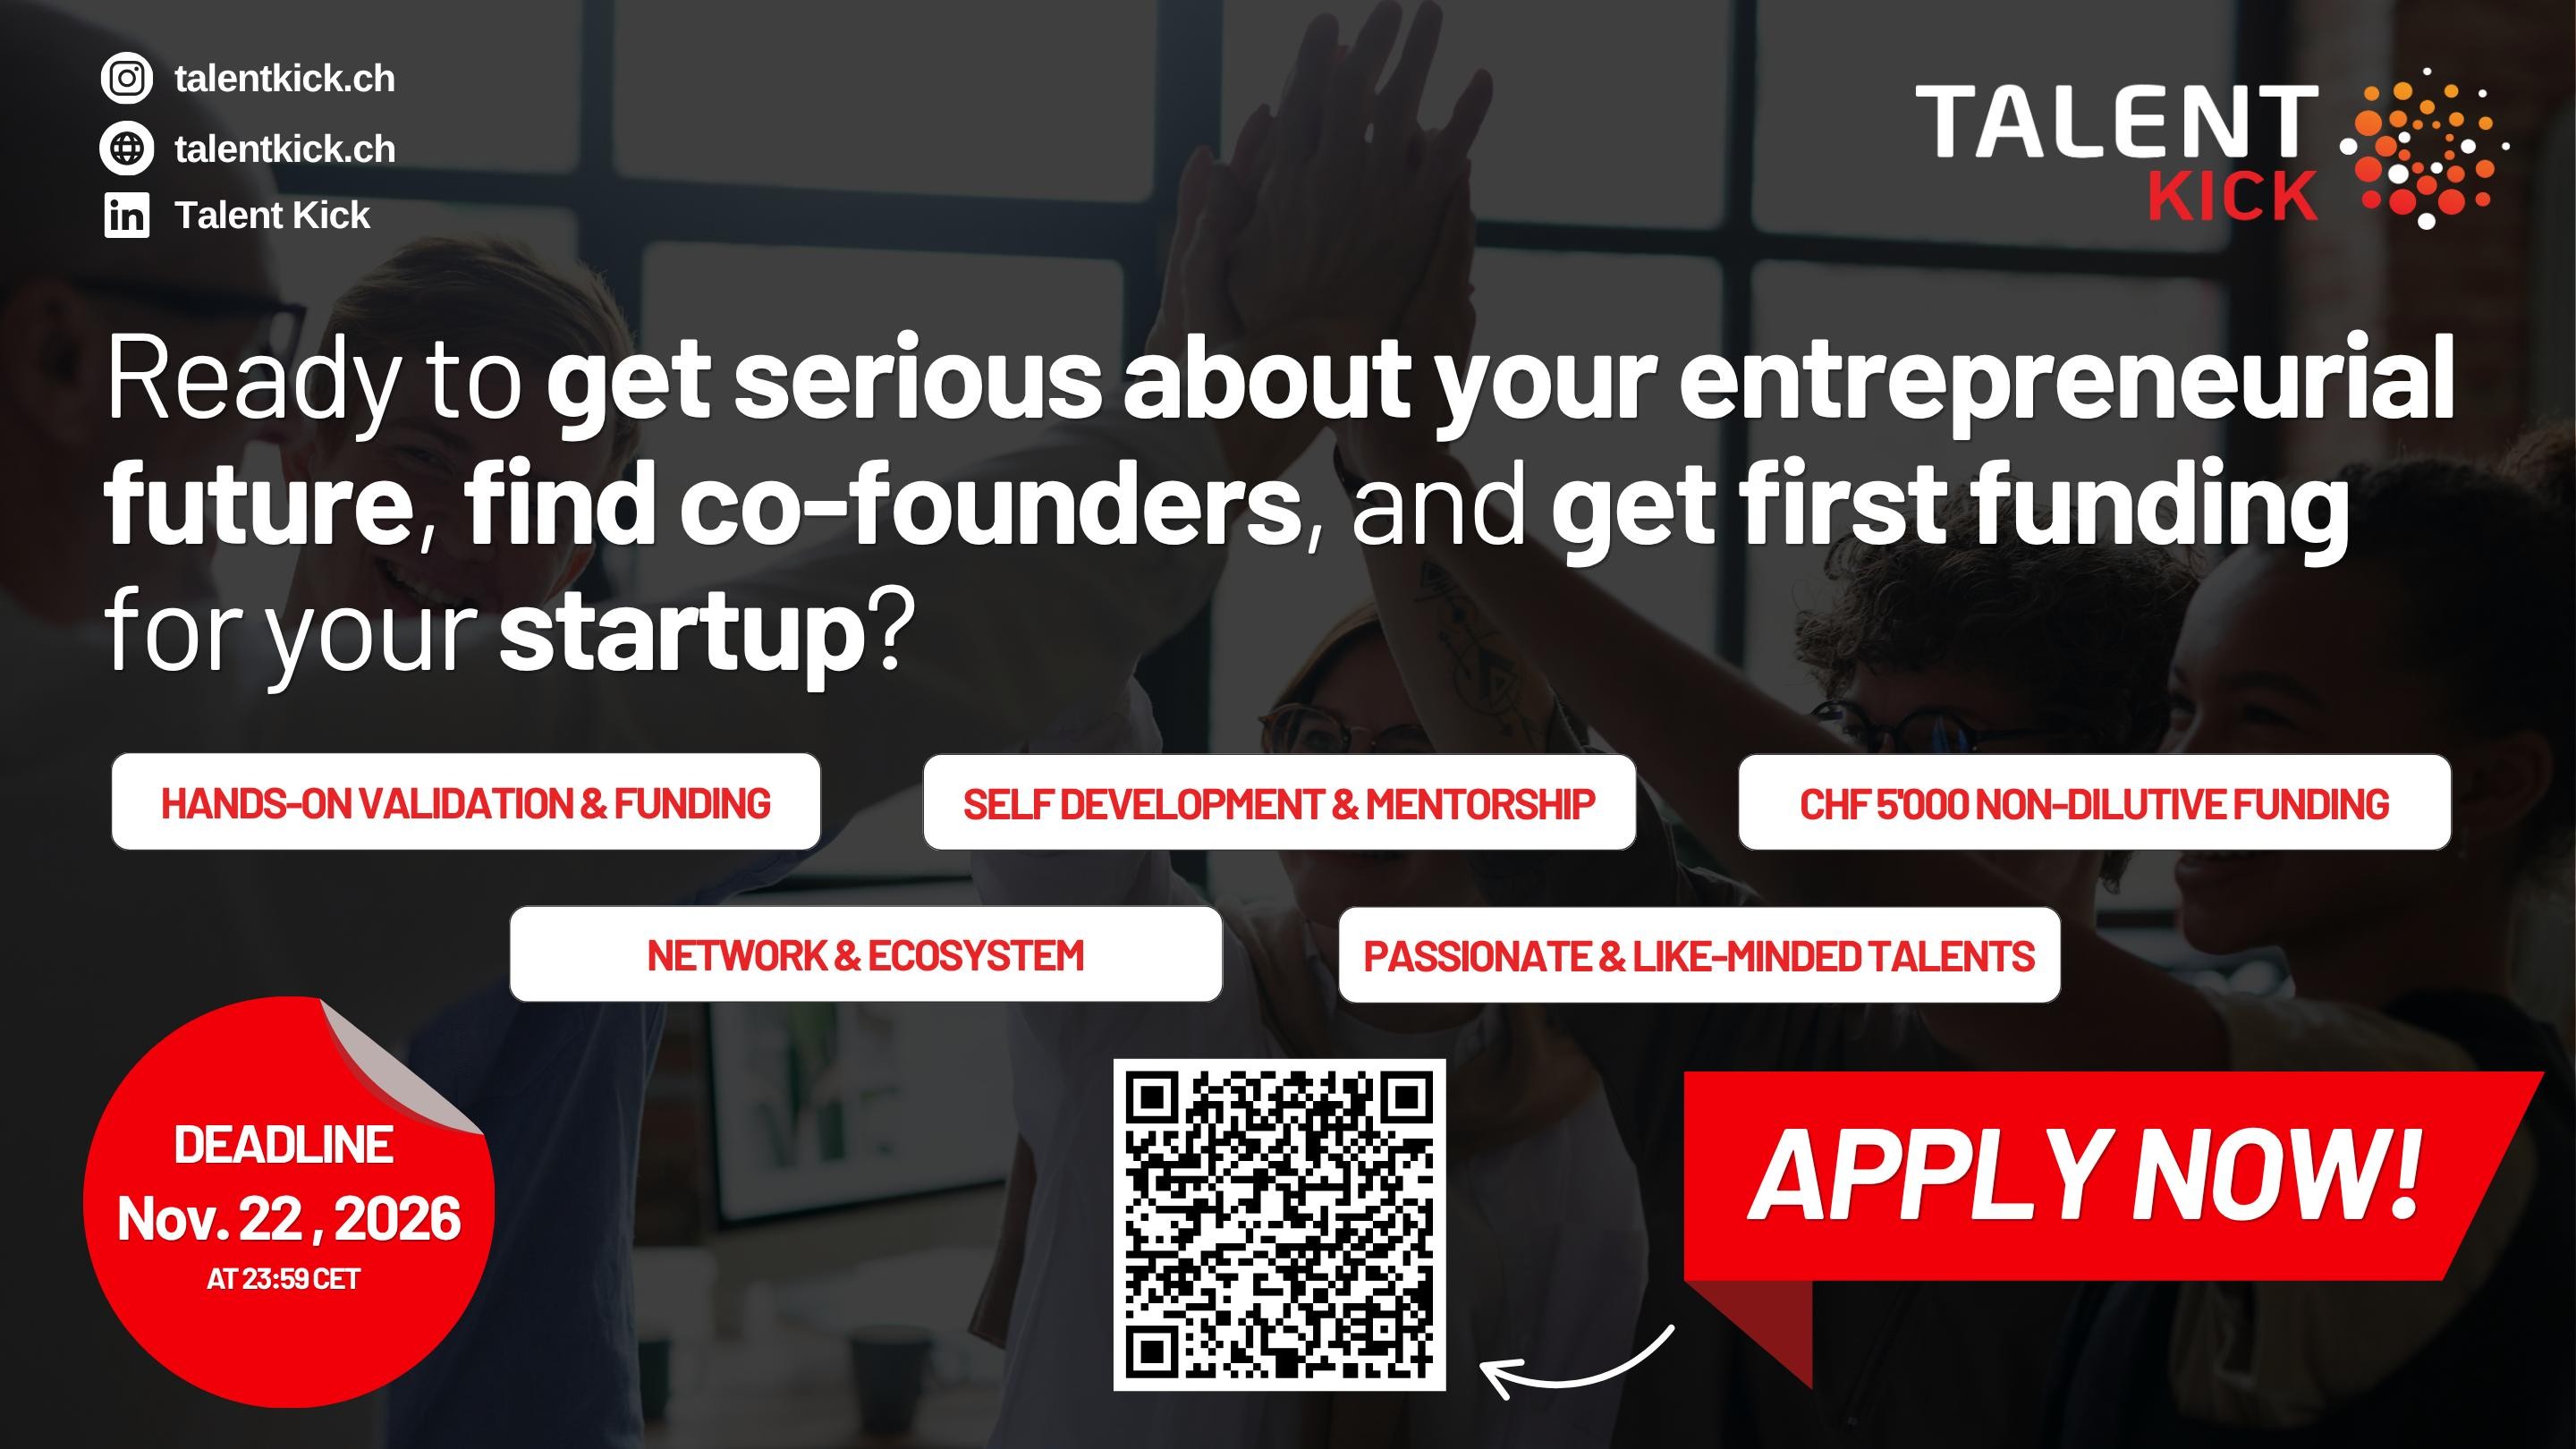
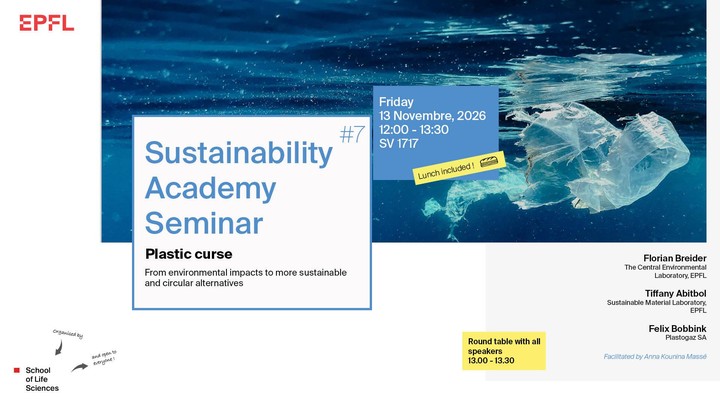
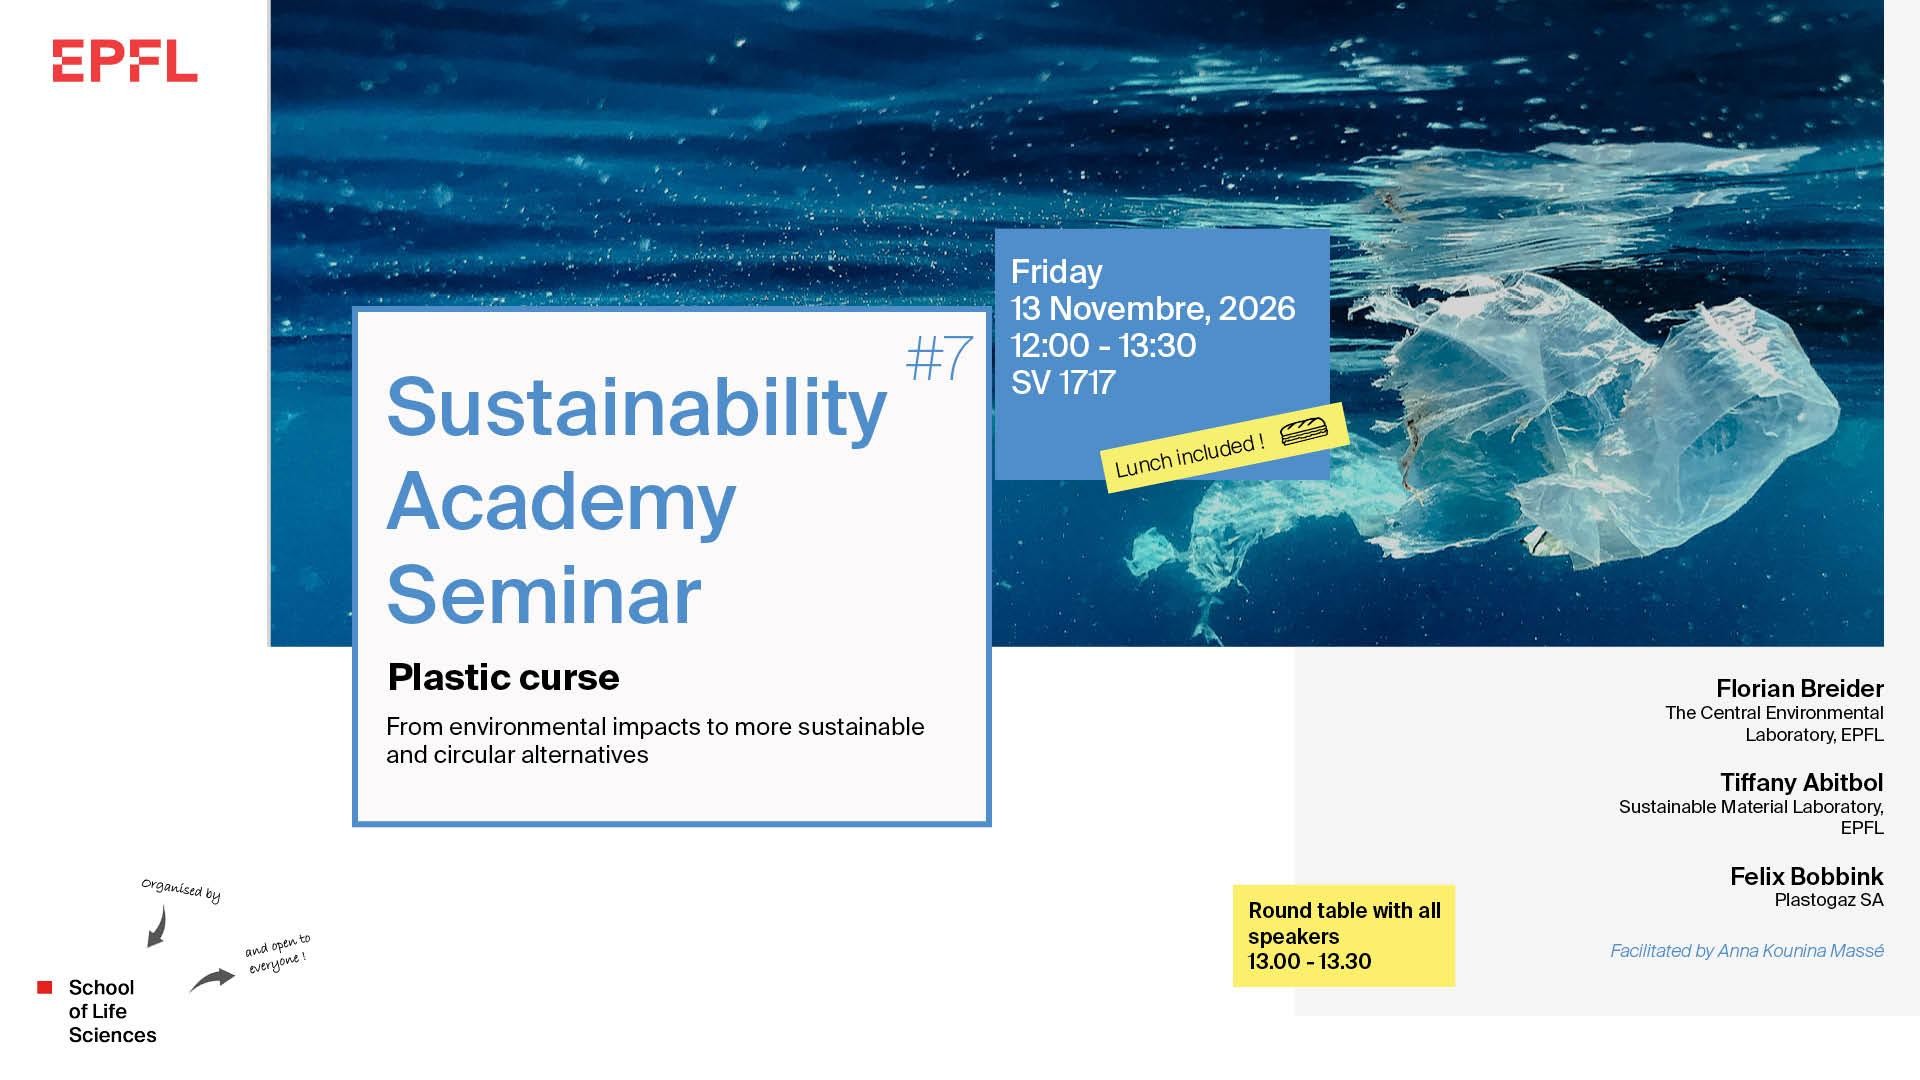
{ "count": 266, "next": "https://memento.epfl.ch/api/v1/events/?format=api&limit=10&offset=120&ordering=event__start_time", "previous": "https://memento.epfl.ch/api/v1/events/?format=api&limit=10&offset=100&ordering=event__start_time", "results": [ { "id": 72469, "title": "Trust, Sensing, and Learning for Provable Multi-Robot Performance", "slug": "trust-sensing-and-learning-for-provable-multi-robo", "event_url": "https://memento.epfl.ch/event/trust-sensing-and-learning-for-provable-multi-robo", "visual_url": "https://memento.epfl.ch/image/33717/200x112.jpg", "visual_large_url": "https://memento.epfl.ch/image/33717/720x405.jpg", "visual_maxsize_url": "https://memento.epfl.ch/image/33717/max-size.jpg", "lang": "en", "start_date": "2026-11-05", "end_date": "2026-11-05", "start_time": "11:00:00", "end_time": "12:00:00", "description": "<p>Multi-robot systems are physically embodied networks — they sense, move, and communicate through the physical world. The bar for safe decision-making rises as these systems enter safety-critical, real-world settings where they must perform well under uncertainty. Our work shows that physicality is a resource against the two kinds of uncertainty they face: intentional (or adversarial), where data is manipulated by malicious agents, and natural, where aspects of the environment are simply unknown. Most of this talk concerns intentional uncertainty. Here, one way to exploit physicality is by using communication as a sensor. Because the signals robots exchange are difficult to forge, they carry evidence that can be cross-validated to yield a quantifiable likelihood that an agent's data is trustworthy. This is the foundation of cy-trust, in which stochastic observations of trust model an agent's trustworthiness probabilistically from physical rather than cryptographic evidence. Each neighbor's contribution is then weighted by its trust value. Under this framework, we show that consensus, distributed optimization, and other core coordination tasks admit almost-sure convergence with bounded deviation from their nominal performance, even when malicious agents exceed half of a node's connectivity, past the classical Byzantine bound. We support this finding with both theory and hardware experiments under adversarial attack. Against natural uncertainty, we show that real-time sensing can be folded into rollout-based reinforcement learning, where the same machinery reweights futures rather than neighbors. We apply this idea to routing a fleet of robots to stochastically appearing demand and, with Project CETI, to the first autonomous robotic rendezvous with sperm whales at sea. Finally, we preview some of our future work combining trust with long-horizon sequential decision-making, targeting planning that stays provably resilient when the data informing the plan may itself be corrupted.<br>\r\n<br>\r\n<em>Stephanie Gil is the John L. Loeb Associate Professor of Engineering and Applied Sciences at Harvard University and an Associate Faculty member of the Kempner Institute. Her research focuses on trust and coordination in multi-robot systems, at the intersection of robotics, communication, and learning. Her contributions have been recognized through the DARPA Young Faculty Award (2024), the Office of Naval Research Young Investigator Award (2021), and the National Science Foundation CAREER Award (2019). She was named a 2020 Sloan Research Fellow for her work at the intersection of robotics and communication. She earned her Ph.D. at CSAIL at MIT, specializing in multi-robot coordination and control, and her B.S. at Cornell University.</em></p>", "image_description": "", "creation_date": "2026-08-31T09:19:27", "last_modification_date": "2026-09-03T18:05:52", "link_label": "", "link_url": "", "canceled": "False", "cancel_reason": "", "place_and_room": "MED 2 1124", "url_place_and_room": "https://plan.epfl.ch/?room==MED%202%201124", "url_online_room": "https://epfl.zoom.us/j/64474989189", "spoken_languages": [ "https://memento.epfl.ch/api/v1/spoken_languages/2/?format=api" ], "speaker": "<a href=\"https://www.linkedin.com/in/stephanie-gil/\">Stephanie Gil</a>", "organizer": "<a href=\"https://www.epfl.ch/research/domains/robotics/\">EPFL Robotics Center</a>", "contact": "<a href=\"https://people.epfl.ch/anca.rusu\">Anca Rusu</a>", "is_internal": "False", "theme": "", "vulgarization": { "id": 2, "fr_label": "Public averti", "en_label": "Informed public" }, "registration": { "id": 3, "fr_label": "Entrée libre", "en_label": "Free" }, "keywords": "", "file": null, "icalendar_url": "https://memento.epfl.ch/event/export/121626/", "category": { "id": 1, "code": "CONF", "fr_label": "Conférences - Séminaires", "en_label": "Conferences - Seminars", "activated": true }, "academic_calendar_category": null, "domains": [], "mementos": [ "https://memento.epfl.ch/api/v1/mementos/1/?format=api", "https://memento.epfl.ch/api/v1/mementos/6/?format=api", "https://memento.epfl.ch/api/v1/mementos/8/?format=api", "https://memento.epfl.ch/api/v1/mementos/417/?format=api" ] }, { "id": 72636, "title": "H∞boys and INDIans: Can they work together for flight control?", "slug": "hboys-and-indians-can-they-work-together-for-fligh", "event_url": "https://memento.epfl.ch/event/hboys-and-indians-can-they-work-together-for-fligh", "visual_url": "https://memento.epfl.ch/image/33880/200x112.jpg", "visual_large_url": "https://memento.epfl.ch/image/33880/720x405.jpg", "visual_maxsize_url": "https://memento.epfl.ch/image/33880/max-size.jpg", "lang": "en", "start_date": "2026-10-07", "end_date": "2026-10-07", "start_time": "11:00:00", "end_time": "12:00:00", "description": "<strong>Abstract</strong><br>\r\nSince the early days of aircraft autopilots, flight control law design has been dominated by gain scheduling: a family of linear controllers designed at trim points across the flight envelope and interpolated as the aerospace vehicle's operating condition changes. The approach is reliable and well understood, but it is also labor-intensive, requiring extensive linearization, controller interpolation, and lengthy re-tuning whenever the airframe or mission profile changes while its classical stability and performance guarantees hold only under restrictive assumptions.<br>\r\n<br>\r\n(Incremental) Nonlinear Dynamic Inversion — (I)NDI — emerged as an attractive alternative, first as full-state NDI in the 1980s–90s and later, in its incremental form, replacing much (though not all) of the reliance on an accurate onboard model with direct sensor feedback of angular acceleration. The result is a simple, largely envelope-independent control structure that (almost) eliminates the scheduling and interpolation burden. The price, however, is the loss of the a priori robustness guarantees that gain-scheduled designs, however cumbersome, were built to provide. Robust control theory, born in the same timeframe as NDI, offers exactly those guarantees, but has traditionally lived in a separate, frequency-domain world from INDI's incremental, time-domain philosophy.<br>\r\n<br>\r\nThis talk shows how the two could be brought closer or even work together. We present hybrid INDI architectures combining a sensor-based and a model-based inversion core and paired with an outer loop tuned via structured synthesis therefore combining the advantages of both worlds. We then generalize this bridge through a formal duality between (I)NDI and quasi-LPV control, unifying robust analysis and synthesis across both worlds and clarifying exactly where INDI's modularity is paid for in achievable robustness. These results are validated across various aerospace applications such as aircraft, space launchers and drones.<br>\r\n<br>\r\n<strong>Biography</strong><br>\r\n<br>\r\nDr. Spilios Theodoulis is an associate professor in the Aerospace GNC cluster within the Control & Simulation (C&S) section, at the Faculty of Aerospace Engineering (AE) of the Delft University of Technology (TU Delft). Before joining TU Delft, he spent fourteen years at the French-German Research Institute of Saint-Louis (ISL), where he was Deputy Head of the GNC department. He is the founder of the Aerospace dynamics and RObust Control (AEROCON) research group along with its advanced projects branch—the ∞-Lab, and also an adjunct professor at the University of Strasbourg, University of Paris-Saclay and Cranfield University teaching tensor-based flight dynamics and automatic (flight) control. He has been involved in the research and development of both civilian and defense projects with EU government agencies, industry and academia in the field of GNC for more than 20 years.<br>\r\n<br>\r\nHis research interests focus on two complementary fields. First, <em>modeling and flight dynamics</em> of complex aerospace systems, including uncertainty modeling and linear/nonlinear-parameter-varying dynamics. Second, (multivariable) <em>stability and</em> <em>control</em> systems spanning from robust/nonlinear control and analysis to control theory-inspired guidance algorithms. The algorithms developed are showcased in several classes of systems (including the facilities of the AE C&S section such as SIMONA, PH-LAB, etc.) such as civil and fighter aircraft, rotorcraft, drones, hypersonic vehicles, space launchers, as well as guided systems. He maintains active collaborations with leading research institutes, including ONERA, DLR, NLR, TNO, NASA, and ESA-ESTEC; academic partners such as ISAE-SUPAERO, Cranfield University, and NYU Abu Dhabi; and industrial partners including Dassault Aviation, Airbus Defence & Space, MBDA, Indra Deimos, PLD Space, Lockheed Martin Skunk Works, and others.<br>\r\n<br>\r\nHe is an Associate Fellow of the American Institute of Aeronautics and Astronautics (Class of 2023), co-recipient of both <em>1-Star</em> and <em>2-Star Innovation Awards</em> (2019) from MBDA, and his students have received (some) distinctions, including the best PhD award in the area of systems and control from the University of Strasbourg (2017). He also serves on various technical committees (AIAA GNC, IFAC Aerospace, CEAS GNC) as well as on the organizing and program conference committees related to the field of GNC (AIAA SciTech, IFAC WC/ACA, EuroGNC, etc.).<br>\r\n<br>\r\nHis most daunting challenge to date though, remains the robust stabilization of his two young daughters Iris and Hera, who are constantly reminding him that nature is neither linear nor time-invariant.<br>\r\n<br>\r\n<br>\r\n ", "image_description": "", "creation_date": "2026-09-22T11:05:26", "last_modification_date": "2026-09-22T16:45:19", "link_label": "", "link_url": "", "canceled": "False", "cancel_reason": "", "place_and_room": "ME C2 405", "url_place_and_room": "https://plan.epfl.ch/?room==ME%20C2%20405", "url_online_room": "", "spoken_languages": [ "https://memento.epfl.ch/api/v1/spoken_languages/2/?format=api" ], "speaker": "<a href=\"https://www.tudelft.nl/en/staff/s.theodoulis/\">Dr. Spilios Theodoulis, associate professor in the Aerospace GNC cluster within the Control & Simulation (C&S) section, at the Faculty of Aerospace Engineering (AE) of the Delft University of Technology (TUDelft), Netherlands</a>", "organizer": "Professor <a href=\"https://people.epfl.ch/alireza.karimi\">Alireza Karimi</a>", "contact": "[email protected]", "is_internal": "False", "theme": "", "vulgarization": { "id": 1, "fr_label": "Tout public", "en_label": "General public" }, "registration": { "id": 3, "fr_label": "Entrée libre", "en_label": "Free" }, "keywords": "", "file": null, "icalendar_url": "https://memento.epfl.ch/event/export/121878/", "category": { "id": 1, "code": "CONF", "fr_label": "Conférences - Séminaires", "en_label": "Conferences - Seminars", "activated": true }, "academic_calendar_category": null, "domains": [], "mementos": [ "https://memento.epfl.ch/api/v1/mementos/8/?format=api", "https://memento.epfl.ch/api/v1/mementos/15/?format=api" ] }, { "id": 72674, "title": "Talent Kick - Build your startup while studying", "slug": "talent-kick-build-your-startup-while-studying", "event_url": "https://memento.epfl.ch/event/talent-kick-build-your-startup-while-studying", "visual_url": "https://memento.epfl.ch/image/33900/200x112.jpg", "visual_large_url": "https://memento.epfl.ch/image/33900/720x405.jpg", "visual_maxsize_url": "https://memento.epfl.ch/image/33900/max-size.jpg", "lang": "en", "start_date": "2026-11-22", "end_date": "2026-11-22", "start_time": "11:00:00", "end_time": "12:00:00", "description": "<p>Are you a student or researcher interested in entrepreneurship? Whether you already have a technology or problem you want to explore, are looking for co-founders, or simply want to discover what building a startup could look like, Talent Kick can help you take the next step.<br>\r\n<br>\r\n<a href=\"https://www.talentkick.ch/\">Talent Kick</a> is a free, cross-university entrepreneurship program that supports students and researchers in exploring promising ideas and technologies, finding co-founders and developing a startup alongside their studies.<br>\r\n<br>\r\nParticipants can benefit from:\r\n</p><ul>\r\n\t<li>up to CHF 5,000 in non-dilutive funding to test and validate their ideas</li>\r\n\t<li>support to find co-founders with complementary skills</li>\r\n\t<li>individual leadership coaching and expert mentorship</li>\r\n\t<li>connections to Switzerland's entrepreneurship and startup ecosystem</li>\r\n</ul>\r\n<strong>Spring 2027 applications</strong><br>\r\n<br>\r\nApplications for the Spring 2027 batch are open until <strong>22 November 2026</strong>. <a href=\"https://www.talentkick.ch/apply?utm_campaign=tk_s27_partners&utm_source=email&utm_medium=link\">Learn more and apply</a><br>\r\n<br>\r\n<strong>Discover Talent Kick at Immersion Day</strong><br>\r\n<br>\r\nCurious about the program before applying? Talent Kick Immersion Day on 14 October 2026 in Zurich brings together students, researchers, founders, alumni and members of the community for a day of founder stories, discussions and networking. Application deadline: <strong>27 September 2026. </strong><a href=\"https://www.talentkick.ch/immersionday2026?utm_campaign=tk_s27_partners&utm_source=email&utm_medium=link\">Learn more about Immersion Day</a>", "image_description": "", "creation_date": "2026-09-25T07:44:50", "last_modification_date": "2026-09-25T07:45:20", "link_label": "Talent Kick", "link_url": "https://www.talentkick.ch/", "canceled": "False", "cancel_reason": "", "place_and_room": "", "url_place_and_room": "", "url_online_room": "", "spoken_languages": [ "https://memento.epfl.ch/api/v1/spoken_languages/2/?format=api" ], "speaker": "", "organizer": "<a href=\"https://www.talentkick.ch/\">Talent Kick</a>", "contact": "<a href=\"mailto:[email protected]\">Cécila Molina</a>", "is_internal": "False", "theme": "", "vulgarization": { "id": 2, "fr_label": "Public averti", "en_label": "Informed public" }, "registration": { "id": 3, "fr_label": "Entrée libre", "en_label": "Free" }, "keywords": "startup; entrepreneurship", "file": null, "icalendar_url": "https://memento.epfl.ch/event/export/121927/", "category": { "id": 16, "code": "PROP", "fr_label": "Appel à proposition", "en_label": "Call for proposal", "activated": true }, "academic_calendar_category": null, "domains": [], "mementos": [ "https://memento.epfl.ch/api/v1/mementos/3/?format=api", "https://memento.epfl.ch/api/v1/mementos/119/?format=api", "https://memento.epfl.ch/api/v1/mementos/422/?format=api" ] }, { "id": 72724, "title": "Designing Social Robots with Older Adults: Context, Adaptation, and Dignity", "slug": "designing-social-robots-with-older-adults-context", "event_url": "https://memento.epfl.ch/event/designing-social-robots-with-older-adults-context", "visual_url": "https://memento.epfl.ch/image/33940/200x112.jpg", "visual_large_url": "https://memento.epfl.ch/image/33940/720x405.jpg", "visual_maxsize_url": "https://memento.epfl.ch/image/33940/max-size.jpg", "lang": "en", "start_date": "2026-11-11", "end_date": "2026-11-11", "start_time": "11:00:00", "end_time": "12:00:00", "description": "<p>How social robots look, behave, and offer support should reflect the people and environments they encounter. Drawing on studies with older adults in rural Indiana and urban Houston, this talk examines how individual needs, preferences, everyday surroundings, and care relationships can inform the physical forms and interaction styles of future social robots.<br>\r\n<br>\r\nThrough participatory design, observations, and interviews, I center older adults’ perspectives on meaningful support, acceptable interaction, and personal boundaries. Encounters with robot companions have brought moments of enjoyment, surprise, and support, while revealing challenges involving communication, expectations, privacy, and control. I explore how embodiment, movement, voice, and interaction pacing shape these experiences, and how caregivers can support engagement while preserving older adults’ choices and dignity.<br>\r\n<br>\r\nThese findings inform design requirements for robots that people can understand, guide, and adjust as their circumstances change. I connect them to opportunities for adaptive robot behavior, accessible interaction, and shared control, including how robots might recognize when assistance is welcome and make their actions easier to interpret or interrupt. The talk positions older adults as active contributors to robotics research, whose lived expertise can shape both future robot companions and the broader systems of support surrounding them.<br>\r\n<br>\r\n<br>\r\n<strong>Biography</strong><br>\r\nChorong Park, Ph.D., is an Assistant Professor and Presidential Frontier Faculty at the University of Houston’s Gerald D. Hines College of Architecture and Design, where she leads the Empathetic Lifespan AI & Robotics for Aging (ELARA) Lab. Her research connects human–robot interaction, human-centered AI, and participatory design to develop social robots and supportive technologies with older adults and caregivers.<br>\r\n<br>\r\nDrawing on studies in rural Indiana and urban Houston, she investigates how robots’ physical forms and interactions can fit older adults’ needs, surroundings, and everyday lives. Her work centers older adults’ perspectives on companionship, support, privacy, personal boundaries, and dignity, including how caregiver involvement can preserve individual choice and control.<br>\r\n<br>\r\nHer research is informed by more than 500 hours of volunteer technology support with older adults and people with disabilities and has appeared at ACM CHI, ACM ASSETS, and IEEE robotics venues. She earned her Ph.D. in Technology, with a graduate minor in Gerontology, and her master’s degree in UX Design from Purdue University.<br>\r\n<br>\r\n<u>Further information</u>:<br>\r\nUniversity of Houston research feature<br>\r\n(<a href=\"https://stories.uh.edu/2026-ai-robots-for-older-adults/index.html\">https://stories.uh.edu/2026-ai-robots-for-older-adults/index.html</a>)<br>\r\nELARA Lab website<br>\r\n(<a href=\"https://elaralab.org/\">https://elaralab.org</a>/)<br>\r\n </p>", "image_description": "", "creation_date": "2026-09-30T16:15:15", "last_modification_date": "2026-09-30T16:25:59", "link_label": "", "link_url": "", "canceled": "False", "cancel_reason": "", "place_and_room": "ME A3 31", "url_place_and_room": "https://plan.epfl.ch/?room==ME%20A3%2031", "url_online_room": "https://epfl.zoom.us/j/69492652047", "spoken_languages": [ "https://memento.epfl.ch/api/v1/spoken_languages/2/?format=api" ], "speaker": "<a href=\"https://elaralab.org/\">Prof. Chorong Park</a>", "organizer": "<a href=\"https://www.epfl.ch/research/domains/robotics/\">Robotics Center</a>", "contact": "<a href=\"https://people.epfl.ch/anca.rusu?lang=en\">Anca Rusu</a>", "is_internal": "False", "theme": "", "vulgarization": { "id": 2, "fr_label": "Public averti", "en_label": "Informed public" }, "registration": { "id": 3, "fr_label": "Entrée libre", "en_label": "Free" }, "keywords": "", "file": null, "icalendar_url": "https://memento.epfl.ch/event/export/122004/", "category": { "id": 1, "code": "CONF", "fr_label": "Conférences - Séminaires", "en_label": "Conferences - Seminars", "activated": true }, "academic_calendar_category": null, "domains": [], "mementos": [ "https://memento.epfl.ch/api/v1/mementos/1/?format=api", "https://memento.epfl.ch/api/v1/mementos/6/?format=api", "https://memento.epfl.ch/api/v1/mementos/8/?format=api", "https://memento.epfl.ch/api/v1/mementos/416/?format=api" ] }, { "id": 72774, "title": "EPFL Valais Wallis Health Day", "slug": "epfl-valais-wallis-health-day", "event_url": "https://memento.epfl.ch/event/epfl-valais-wallis-health-day", "visual_url": "https://memento.epfl.ch/image/33990/200x112.jpg", "visual_large_url": "https://memento.epfl.ch/image/33990/720x405.jpg", "visual_maxsize_url": "https://memento.epfl.ch/image/33990/max-size.jpg", "lang": "en", "start_date": "2026-11-10", "end_date": "2026-11-10", "start_time": "11:00:00", "end_time": "19:00:00", "description": "<p>Following the success of the Unil+EFPL Health Days on the Ecublens campus, the EPFL Valais Wallis campus will host its first Health Day in Sion, featuring health check-ups and tests, information booths, workshops, and an expert talk.<br>\r\n<br>\r\n<strong>11:00-14:30 – Health Check-ups & Tests, Innovation & Sports</strong>\r\n</p><ul>\r\n\t<li>Joint Mobility</li>\r\n\t<li>Cardiovascular</li>\r\n\t<li>Anthropometry</li>\r\n\t<li>The Secrets of Pendulum Exercises</li>\r\n</ul>\r\n<br>\r\n<strong>11:00-14:30 – Prevention, Resources & Support</strong>\r\n\r\n<ul>\r\n\t<li>Swiss Polar Institute</li>\r\n\t<li>EPFL Well-being and Inclusion</li>\r\n\t<li>Accident Prevention Module for Snow Sports</li>\r\n</ul>\r\n<br>\r\n<strong>11:00-14:00 – Interactive Sessions on Respect and Well-being (EN)</strong><br>\r\nby Ingrid Le Duc, ENAC Dean’s Delegate for Organizational Culture\r\n<ul>\r\n\t<li>Managing Stress in an Academic Environment</li>\r\n\t<li>Understanding and Responding to Powersplaining and Mansplaining</li>\r\n\t<li>Balancing Pressure and Productivity in Academia</li>\r\n\t<li>Repairing Interactions When Implicit Bias Shapes the Conversation</li>\r\n</ul>\r\n<br>\r\n<strong>16:00-17:00 –</strong> <strong>Workshop (EN): The Power of Effective Breaks</strong><br>\r\nby Diane Duperret, sophrologist<br>\r\n<br>\r\n<br>\r\n<strong>17:00-18:00 – Expert Talk (EN): The Stressed Brain, From Emotion to Performance</strong><br>\r\nby Prof. Chantal Martin Sölch (University of Fribourg)<br>\r\n<br>\r\nFollowed by a reception<br>\r\n<br>\r\n<br>\r\n<a href=\"https://www.epfl.ch/campus/security-safety/sante/sante-mentale-bien-etre/journees-sante-campus-associes/\">>> Details and registration</a>", "image_description": "", "creation_date": "2026-10-06T11:42:12", "last_modification_date": "2026-10-06T11:57:16", "link_label": "Details and registration", "link_url": "https://www.epfl.ch/campus/security-safety/en/health/mental-health-well-being/health-day-associated-campuses/", "canceled": "False", "cancel_reason": "", "place_and_room": "ALPOLE", "url_place_and_room": "", "url_online_room": "", "spoken_languages": [ "https://memento.epfl.ch/api/v1/spoken_languages/1/?format=api", "https://memento.epfl.ch/api/v1/spoken_languages/2/?format=api" ], "speaker": "Ingrid Le Duc, Diane Duperret, Chantal Martin Sölch", "organizer": "EPFL Valais Wallis, EPFL VPH-WINC", "contact": "<a href=\"mailto:[email protected]\">[email protected]</a>", "is_internal": "True", "theme": "", "vulgarization": { "id": 1, "fr_label": "Tout public", "en_label": "General public" }, "registration": { "id": 3, "fr_label": "Entrée libre", "en_label": "Free" }, "keywords": "", "file": null, "icalendar_url": "https://memento.epfl.ch/event/export/122078/", "category": { "id": 1, "code": "CONF", "fr_label": "Conférences - Séminaires", "en_label": "Conferences - Seminars", "activated": true }, "academic_calendar_category": null, "domains": [], "mementos": [ "https://memento.epfl.ch/api/v1/mementos/5/?format=api", "https://memento.epfl.ch/api/v1/mementos/8/?format=api", "https://memento.epfl.ch/api/v1/mementos/9/?format=api", "https://memento.epfl.ch/api/v1/mementos/425/?format=api", "https://memento.epfl.ch/api/v1/mementos/396/?format=api", "https://memento.epfl.ch/api/v1/mementos/110/?format=api", "https://memento.epfl.ch/api/v1/mementos/21/?format=api", "https://memento.epfl.ch/api/v1/mementos/6/?format=api" ] }, { "id": 72610, "title": "Meet the TTO - October 2026", "slug": "meet-the-tto-october-2026", "event_url": "https://memento.epfl.ch/event/meet-the-tto-october-2026", "visual_url": "https://memento.epfl.ch/image/33855/200x112.jpg", "visual_large_url": "https://memento.epfl.ch/image/33855/720x405.jpg", "visual_maxsize_url": "https://memento.epfl.ch/image/33855/max-size.jpg", "lang": "en", "start_date": "2026-10-15", "end_date": "2026-10-15", "start_time": "11:30:00", "end_time": "12:15:00", "description": "<strong>A monthly gathering with the Technology Transfer Office team in a relaxed and informal setting.</strong><br>\r\n<br>\r\nConnect with the team to explore intellectual property, strategies for creating commercial value from your academic work, and technology transfer practices.<br>\r\n<br>\r\nDiscussions may cover\r\n<ul>\r\n\t<li>the inventive aspects of your research,</li>\r\n\t<li>patenting and commercial potential,</li>\r\n\t<li>software and AI/ML use,</li>\r\n\t<li>training data,</li>\r\n\t<li>and licensing terms for startups and companies.</li>\r\n</ul>\r\n<strong>Access:</strong> Open to the EPFL community (startup excluded)<br>\r\n<br>\r\n<strong>Upcoming dates</strong>: 12 November, and 10 December 2026", "image_description": "", "creation_date": "2026-09-17T14:35:33", "last_modification_date": "2026-09-17T15:07:31", "link_label": "webpage", "link_url": "https://www.epfl.ch/research/technology-transfer/explore-ask-learn-with-your-tto/", "canceled": "False", "cancel_reason": "", "place_and_room": "KNOVA, Building J, 2nd floor, EPFL Innovation Park", "url_place_and_room": "https://plan.epfl.ch/?room==QIJ%202%20138", "url_online_room": "", "spoken_languages": [ "https://memento.epfl.ch/api/v1/spoken_languages/2/?format=api" ], "speaker": "", "organizer": "<a href=\"https://www.epfl.ch/research/technology-transfer/\">EPFL TTO</a>", "contact": "<a href=\"mailto:[email protected]\">Bea Arnold</a> & <a href=\"mailto:[email protected]\">Lucia Pavan</a>", "is_internal": "True", "theme": "", "vulgarization": { "id": 2, "fr_label": "Public averti", "en_label": "Informed public" }, "registration": { "id": 3, "fr_label": "Entrée libre", "en_label": "Free" }, "keywords": "intellectual property; IP; commercial value; technology transfer", "file": null, "icalendar_url": "https://memento.epfl.ch/event/export/121846/", "category": { "id": 15, "code": "FORM", "fr_label": "Formations internes", "en_label": "Internal trainings", "activated": true }, "academic_calendar_category": null, "domains": [], "mementos": [ "https://memento.epfl.ch/api/v1/mementos/1/?format=api", "https://memento.epfl.ch/api/v1/mementos/3/?format=api", "https://memento.epfl.ch/api/v1/mementos/4/?format=api", "https://memento.epfl.ch/api/v1/mementos/5/?format=api", "https://memento.epfl.ch/api/v1/mementos/6/?format=api", "https://memento.epfl.ch/api/v1/mementos/8/?format=api", "https://memento.epfl.ch/api/v1/mementos/9/?format=api", "https://memento.epfl.ch/api/v1/mementos/119/?format=api" ] }, { "id": 69355, "title": "Sustainable Academy Seminar #7 Plastic Curse", "slug": "sustainable-academy-seminar-7-plastic-curse", "event_url": "https://memento.epfl.ch/event/sustainable-academy-seminar-7-plastic-curse", "visual_url": "https://memento.epfl.ch/image/30871/200x112.jpg", "visual_large_url": "https://memento.epfl.ch/image/30871/720x405.jpg", "visual_maxsize_url": "https://memento.epfl.ch/image/30871/max-size.jpg", "lang": "en", "start_date": "2026-11-13", "end_date": "2026-11-13", "start_time": "12:00:00", "end_time": "13:30:00", "description": "<br>\r\nThe School of Life Sciences and SV Sustainability are delighted to welcome <strong>Florian Breider, Tiffany Abitbol, and Felix Bobbink</strong> for the <strong>7<sup>th </sup>edition of the Sustainable Academy</strong>, dedicated to the theme <strong>“The Plastic Curse.” </strong><br>\r\n<br>\r\nPlastic has become an integral part of our daily lives. In fact, it is now often more difficult to find objects without plastic than with it. While plastic offers many advantages, including its versatility, durability, lightweight nature, and low cost, its production and disposal have significant environmental consequences. Plastic pollution poses major threats to ecosystems, biodiversity, and human health.<br>\r\n<br>\r\nResearch activities, particularly in the life sciences, rely heavily on plastic because of its numerous practical benefits. However, despite the challenges associated with managing plastic waste and closing material loops, more sustainable materials and circular solutions are emerging. <br>\r\n<br>\r\nWhether you are a scientist, student, or simply curious about the issue, this seminar will provide valuable insights into plastic use at EPFL, the impacts of plastic pollution on our environment and health, promising alternative materials, and innovative recycling approaches, including a perspective on chemical recycling from Plastogaz. <br>\r\n<br>\r\n Don't miss out on this unique opportunity to learn, connect, and be inspired! And don't forget to <a href=\"https://docs.google.com/forms/d/e/1FAIpQLSdL_DORscs9PtEdvx4Y1qZ79Ag6rC9maU6hzjLUfeQz0pnuwA/viewform?usp=header\">register</a>. <br>\r\n ", "image_description": "", "creation_date": "2025-06-24T13:59:04", "last_modification_date": "2026-10-05T09:49:20", "link_label": "Register here!", "link_url": "https://docs.google.com/forms/d/e/1FAIpQLSdL_DORscs9PtEdvx4Y1qZ79Ag6rC9maU6hzjLUfeQz0pnuwA/viewform?usp=publish-editor", "canceled": "False", "cancel_reason": "", "place_and_room": "SV 1717", "url_place_and_room": "https://plan.epfl.ch/?room==SV%201717", "url_online_room": "", "spoken_languages": [ "https://memento.epfl.ch/api/v1/spoken_languages/2/?format=api" ], "speaker": "", "organizer": "SV Sustainability ", "contact": "<a href=\"https://people.epfl.ch/mai-phuong.dinh\">Mai-Phuong Dinh </a>", "is_internal": "False", "theme": "", "vulgarization": { "id": 1, "fr_label": "Tout public", "en_label": "General public" }, "registration": { "id": 1, "fr_label": "Sur inscription", "en_label": "Registration required" }, "keywords": "Sustainability, Health, Environment, Toxicology, Plastic pollution, plastic", "file": null, "icalendar_url": "https://memento.epfl.ch/event/export/116971/", "category": { "id": 1, "code": "CONF", "fr_label": "Conférences - Séminaires", "en_label": "Conferences - Seminars", "activated": true }, "academic_calendar_category": null, "domains": [], "mementos": [ "https://memento.epfl.ch/api/v1/mementos/79/?format=api", "https://memento.epfl.ch/api/v1/mementos/9/?format=api", "https://memento.epfl.ch/api/v1/mementos/1/?format=api", "https://memento.epfl.ch/api/v1/mementos/145/?format=api", "https://memento.epfl.ch/api/v1/mementos/4/?format=api", "https://memento.epfl.ch/api/v1/mementos/5/?format=api", "https://memento.epfl.ch/api/v1/mementos/8/?format=api" ] }, { "id": 69765, "title": "ISIC Faculty Lunch", "slug": "isic-faculty-lunch-7", "event_url": "https://memento.epfl.ch/event/isic-faculty-lunch-7", "visual_url": "https://memento.epfl.ch/image/31251/200x112.jpg", "visual_large_url": "https://memento.epfl.ch/image/31251/720x405.jpg", "visual_maxsize_url": "https://memento.epfl.ch/image/31251/max-size.jpg", "lang": "en", "start_date": "2026-11-13", "end_date": "2026-11-13", "start_time": "12:00:00", "end_time": "14:00:00", "description": "<strong>President Anna Fontcuberta </strong>and<strong> Mrs. Françoise Bommensatt (VP for Finance) </strong>will be introducing Nexus to all of you. <br>\r\n<br>\r\n<strong>Agenda</strong><br>\r\n12:10 – 12:30 25th Institute Anniversary<br>\r\n12:30 – 14:00 Standing Lunch", "image_description": "", "creation_date": "2025-09-09T11:23:01", "last_modification_date": "2026-08-28T16:33:10", "link_label": "", "link_url": "", "canceled": "False", "cancel_reason": "", "place_and_room": "Copernic", "url_place_and_room": "https://plan.epfl.ch/?room==CE%201%20711.1", "url_online_room": "", "spoken_languages": [ "https://memento.epfl.ch/api/v1/spoken_languages/2/?format=api" ], "speaker": "<a href=\"https://people.epfl.ch/anna.fontcuberta-morral\">Prof. Anna Fontcuberta</a>, EPFL President\r\n\r\n<a href=\"https://people.epfl.ch/francoise.bommensatt\">Mrs. Françoise Bommensatt</a>,<strong> </strong>Vice President for Finance", "organizer": "<a href=\"https://www.epfl.ch/schools/sb/research/isic/\">Institute of Chemical Sciences and Engineering – ISIC</a>", "contact": "<a href=\"https://people.epfl.ch/marta.ruizcumi\">Marta Ruiz Cumi</a>", "is_internal": "True", "theme": "", "vulgarization": { "id": 2, "fr_label": "Public averti", "en_label": "Informed public" }, "registration": { "id": 2, "fr_label": "Sur invitation", "en_label": "Invitation required" }, "keywords": "ISICIntranet", "file": null, "icalendar_url": "https://memento.epfl.ch/event/export/117576/", "category": { "id": 1, "code": "CONF", "fr_label": "Conférences - Séminaires", "en_label": "Conferences - Seminars", "activated": true }, "academic_calendar_category": null, "domains": [], "mementos": [ "https://memento.epfl.ch/api/v1/mementos/14/?format=api" ] }, { "id": 72376, "title": "SUPER SANDWICH SEMINAR", "slug": "super-sandwich-seminar-380", "event_url": "https://memento.epfl.ch/event/super-sandwich-seminar-380", "visual_url": "https://memento.epfl.ch/image/33632/200x112.jpg", "visual_large_url": "https://memento.epfl.ch/image/33632/720x405.jpg", "visual_maxsize_url": "https://memento.epfl.ch/image/33632/max-size.jpg", "lang": "en", "start_date": "2026-10-08", "end_date": "2026-10-08", "start_time": "12:00:00", "end_time": "13:00:00", "description": "<p>Triple S (Super Sandwich Seminar) will feature three speakers per week, each giving a 15-minute presentation followed by a 5-minute Q&A session.</p>", "image_description": "", "creation_date": "2026-08-19T11:41:26", "last_modification_date": "2026-08-19T14:19:10", "link_label": "", "link_url": "", "canceled": "False", "cancel_reason": "", "place_and_room": "SV 1717", "url_place_and_room": "https://plan.epfl.ch/?room==SV%201717", "url_online_room": "", "spoken_languages": [ "https://memento.epfl.ch/api/v1/spoken_languages/2/?format=api" ], "speaker": "Lei Huang<em>, Constam Lab</em>; Nika Gorsek <em>D'Angelo Lab;</em> <strong><em>free slot</em></strong>", "organizer": "Prof. Pierre Gönczy", "contact": "Lisa Smith, ISREC Administrative Assistant", "is_internal": "True", "theme": "", "vulgarization": { "id": 2, "fr_label": "Public averti", "en_label": "Informed public" }, "registration": { "id": 3, "fr_label": "Entrée libre", "en_label": "Free" }, "keywords": "Super Sandwich, cancer", "file": null, "icalendar_url": "https://memento.epfl.ch/event/export/121483/", "category": { "id": 1, "code": "CONF", "fr_label": "Conférences - Séminaires", "en_label": "Conferences - Seminars", "activated": true }, "academic_calendar_category": null, "domains": [], "mementos": [ "https://memento.epfl.ch/api/v1/mementos/1/?format=api", "https://memento.epfl.ch/api/v1/mementos/6/?format=api", "https://memento.epfl.ch/api/v1/mementos/8/?format=api", "https://memento.epfl.ch/api/v1/mementos/9/?format=api", "https://memento.epfl.ch/api/v1/mementos/26/?format=api" ] }, { "id": 72452, "title": "MechE Colloquium: From Motion to Mission Planning via Augmented Graphs of Convex Sets", "slug": "meche-colloquium-from-motion-to-mission-planning-v", "event_url": "https://memento.epfl.ch/event/meche-colloquium-from-motion-to-mission-planning-v", "visual_url": "https://memento.epfl.ch/image/33700/200x112.jpg", "visual_large_url": "https://memento.epfl.ch/image/33700/720x405.jpg", "visual_maxsize_url": "https://memento.epfl.ch/image/33700/max-size.jpg", "lang": "en", "start_date": "2026-10-06", "end_date": "2026-10-06", "start_time": "12:00:00", "end_time": "13:00:00", "description": "<strong>Abstract: </strong>Robot motion planning has traditionally focused on navigating obstacle-laden environments: computing smooth, collision-free trajectories from start to goal. Many real-world missions, however, require satisfying logical precedence constraints: collecting resources before accessing restricted zones, completing subtasks in a prescribed order, or acquiring tools before they can be used. This talk presents the augmented graph of convex sets (augmented GCS) framework, which unifies continuous trajectory optimization and combinatorial task sequencing within a single optimization problem.<br>\r\nThe key insight is that a layered augmented GCS, built on an exact convex partition of the free space, simultaneously selects an optimal task completion sequence and computes an optimal continuous trajectory. A shortest path in the augmented GCS solves both problems at once, yielding an exact solution up to a finite Bézier curve parameterization. The layered structure of the augmented GCS turns out to implement precisely the Bellman-Held-Karp (BHK) dynamic programming algorithm for the Traveling Salesman Problem, establishing a formal correspondence between our framework and the combinatorial TSP literature. This makes augmented GCS a continuous-geometry generalization of BHK, achieving the same singly exponential worst-case complexity, an exponential improvement over general-purpose temporal logic tools. We further develop a library of mission specification variations (including ordered collection, disjunctive keys, conjunctive doors, timed constraints, and conditional logic) each with proven correctness, substantially expanding the range of expressible mission types. Numerical experiments confirm exponential speedups in practice and near-global-optimality on a large benchmark suite.<br>\r\nTime permitting, I will briefly discuss ongoing extensions, including spacetime augmented GCS for dynamic environments, safety-aware planning via conformal prediction sets, and a galactic survey benchmark inspired by space mission planning that stress-tests the framework at scale.<br>\r\n<br>\r\n<br>\r\n<br>\r\n<strong>Biography: </strong>Tyler Summers is an associate professor at the University of Texas at Dallas. Prior to joining UT Dallas, he was an ETH Postdoctoral Fellow at the Automatic Control Laboratory at ETH Zurich from 2011 to 2015. He received a PhD degree in Aerospace Engineering at the University of Texas at Austin in 2010. He was a Fulbright Postgraduate Scholar at the Australian National University in Canberra, Australia in 2007-2008. He received the National Science Foundation CAREER Award in 2021 and a Young Investigator Program award from the US Army Research Office in 2017. His research interests are in feedback control, optimization, and learning in complex dynamical networks, with applications in robotics and power networks.", "image_description": "", "creation_date": "2026-08-26T16:15:39", "last_modification_date": "2026-08-26T16:19:15", "link_label": "", "link_url": "", "canceled": "False", "cancel_reason": "", "place_and_room": "MED 0 1418", "url_place_and_room": "https://plan.epfl.ch/?room==MED%200%201418", "url_online_room": "https://epfl.zoom.us/j/61360740951", "spoken_languages": [ "https://memento.epfl.ch/api/v1/spoken_languages/2/?format=api" ], "speaker": "<a href=\"https://me.utdallas.edu/faculty/tyler-summers/\">Prof. Tyler Summers</a>, <a href=\"https://me.utdallas.edu/\">Mechanical engineering,</a> <a href=\"https://www.utdallas.edu/\">The University of Texas at Dallas</a>", "organizer": "<a href=\"https://people.epfl.ch/maryam.kamgarpour\">Prof. Maryam Kamgarpour</a>", "contact": "<a href=\"mailto:[email protected]\">Institute of Mechanical Engineering</a>", "is_internal": "False", "theme": "", "vulgarization": { "id": 1, "fr_label": "Tout public", "en_label": "General public" }, "registration": { "id": 3, "fr_label": "Entrée libre", "en_label": "Free" }, "keywords": "MechE Colloquium: From Motion to Mission Planning via Augmented Graphs of Convex Sets", "file": null, "icalendar_url": "https://memento.epfl.ch/event/export/121601/", "category": { "id": 1, "code": "CONF", "fr_label": "Conférences - Séminaires", "en_label": "Conferences - Seminars", "activated": true }, "academic_calendar_category": null, "domains": [], "mementos": [ "https://memento.epfl.ch/api/v1/mementos/8/?format=api", "https://memento.epfl.ch/api/v1/mementos/1/?format=api", "https://memento.epfl.ch/api/v1/mementos/232/?format=api", "https://memento.epfl.ch/api/v1/mementos/270/?format=api", "https://memento.epfl.ch/api/v1/mementos/6/?format=api", "https://memento.epfl.ch/api/v1/mementos/417/?format=api", "https://memento.epfl.ch/api/v1/mementos/394/?format=api" ] } ] }